BrainCo Revo 2 — a dexterous hand your agent can actually grasp with
The BrainCo Revo 2 dexterous hand now has a driver: open and close, per-finger positions, preset gestures, live joint telemetry, LED and button events, and fingertip touch on the tactile model — with two hands on one bus.
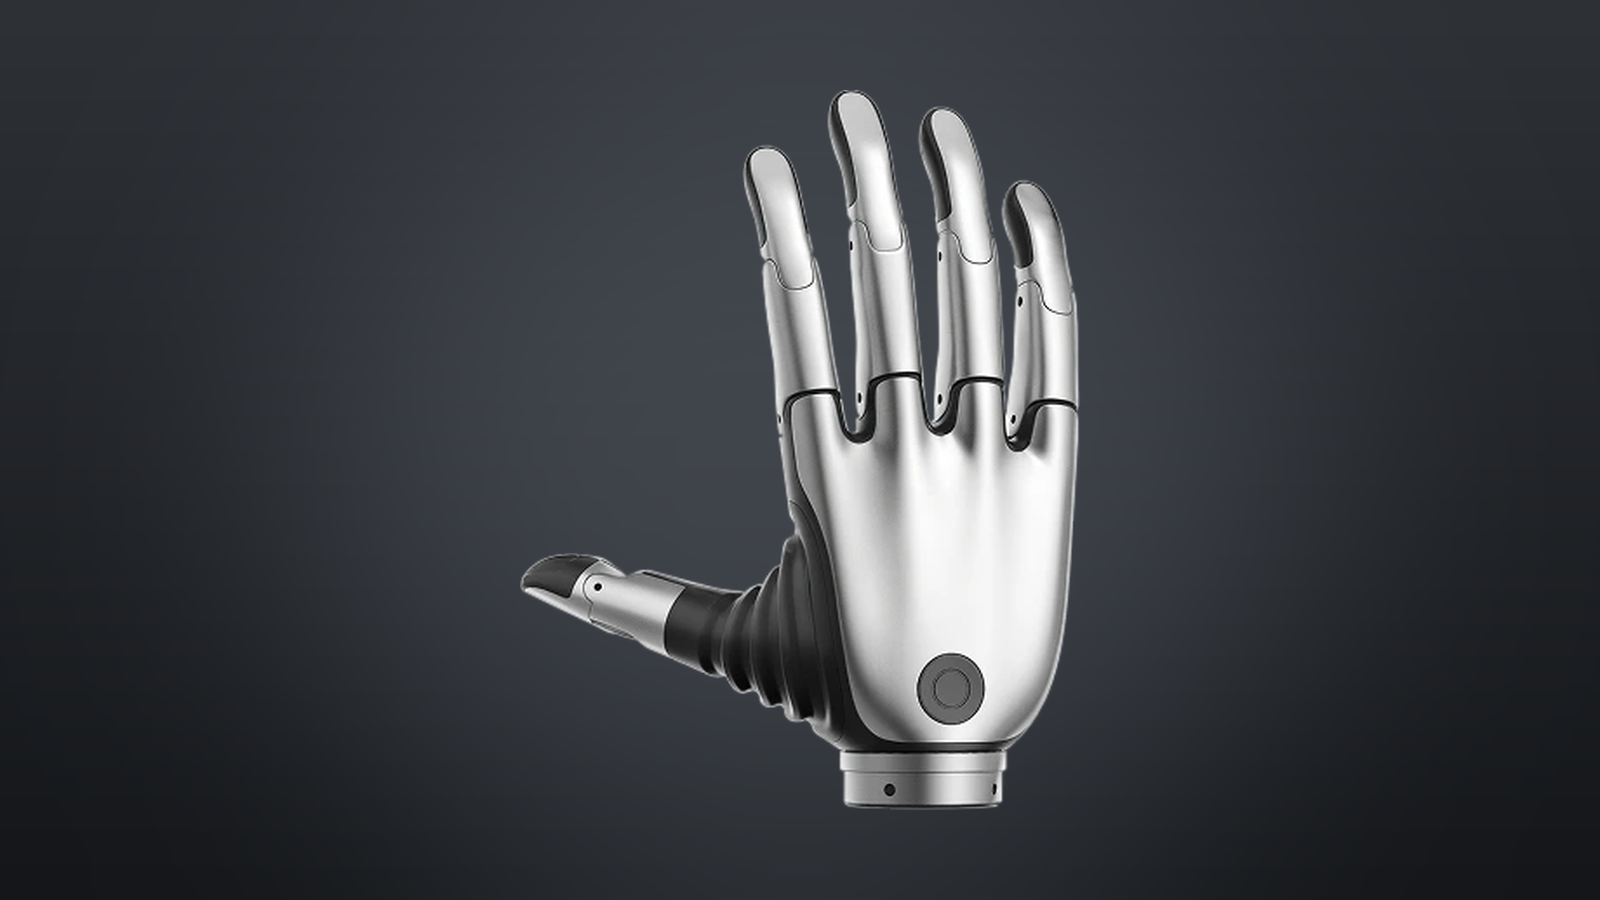
From "the arm reaches" to "the hand holds"
An arm can get to an object; picking it up is the hand's job. The Revo 2 driver puts a five-finger hand in your agent's tool list — open, close, a specific pose per finger, or a named gesture — and streams what the hand is doing back to the dashboard while it does it.
What you get
- Positions in one scale that never flips. Every command uses 0 = fully open, 1000 = fully closed, for a single finger or all of them at once. No per-joint sign conventions to remember.
- Gestures by name.
open,fist,pinch_two,pinch_three,pinch_sideandpointrun as one call, so "pinch it" doesn't have to be spelled out finger by finger. - Live telemetry. A state card polls the hand about every 0.15 s and publishes joint positions as JSON, so the dashboard shows the grip closing in real time.
- Feel, on the tactile model. The touch card loads only for the tactile variant and publishes fingertip contact data.
- Both hands, one bus. Left and right can share a single RS-485 or CAN FD bus — pick a side and a device address (they ship as 126 and 127).
- LED and button. Set the status light, and read the button events a human presses on the hand itself.
The hardware
Six active joints across 11 degrees of freedom, 383 g without the wrist, 160 mm tall. Full-hand grip is ≥50 N, single-finger pinch ≥15 N, and the hand can carry ≥20 kg. Flexion or extension takes ≤0.65 s, repeat positioning is accurate to 0.1°, maximum span is 100 mm, and it runs under 50 dB. Three models are available — base, advanced and tactile, the last adding multi-dimensional fingertip sensing. It connects over RS-485 or CAN FD.
Getting started
Deploy the BrainCo Revo 2 driver from the console (port 15706), pick the side, bus and variant in the card's config, then drop the hand and state cards onto the canvas.
Calibrate once after every power-on. The hand ignores position commands until it has been calibrated, and calibration spreads all five fingers — clear the hand of objects and keep fingers away from it before you run it.