


Core
Agent Core
Requiresarm64
+420
Published Sep 11, 2026
PhanthyMotus is a next-generation, open-source framework and platform for Embodied AI Agents. Built upon a robust ROS2 foundation, it seamlessly bridges diverse sensor inputs with advanced robot execution. By enabling flexible integration of World Models, LLMs, and VLMs, PhanthyMotus transforms traditional hardware into soulful, intelligent assistants capable of perceiving, thinking, and acting independently in the real world.
A Unified Embodied Agent Platform
Dozens of robot brands supported — humanoids, quadrupeds, wheeled, drones, arms, and underwater vehicles
Why PhanthyMotus
Drop the remote control. PhanthyMotus enables robots to understand their environment, plan actions, and execute tasks autonomously — truly becoming intelligent assistants in everyday life.
Production-Ready ROS2 Core
Native compatibility with mainstream robotic hardware ecosystems
Modular & Extensible Architecture
Plug in custom perception and decision-making models effortlessly
User-Centric Autonomy
Robots autonomously complete real-world tasks
Pluggable Multi-Model Framework
Flexible integration of World Models, LLMs, and VLMs
Full-Stack Agent Architecture
Long-term memory, dynamic skill library, continuous Agent Loop
Unified Sensor & Actuator Interface
Multi-sensor fusion and precise motor control
Hardware Scalability
Humanoids, quadrupeds, robotic arms, wheeled platforms, drones
Skill Scalability
Continuously train, import, and stack new skills
AI Model Scalability
Seamlessly upgrade to the latest perception and decision models
Zero-Config Discovery
Peers find each other over LAN, offline mesh, or across sites
Shared Peer Capabilities
A peer's sensors and actuators become your agent's tools
Short-Code Pairing Security
Key-based identity, six-digit pairing on both sides, roles that default to read-only
Architecture
Peer Mesh & Security
Platform Preview
Add sensors and actuators onto the canvas, connect them to the Agent Loop — the framework handles data flow and execution automatically, like building blocks
Audio waveforms, battery status, 3D skeleton and point cloud visualization
Identity setup, system prompt, and long-term memory editing online
Deploy and manage Agent Core and hardware driver containers
All Resources · 21 available · 331 cards
Production-grade images, reviewed and ARM64 ready.
Published Sep 11, 2026
Unitree Go2 — 运动控制 + 避障 + 语音 + 视频 + 拍照/录像采集 + RealSense 深度/红外 + 导航
Published Sep 11, 2026
ARM64 RealMan RM75-6F-V state, joint motion, two-finger gripper, and upper-computer RealSense camera Driver
Published Sep 11, 2026
Noetix Bumi-EDU — 麦克风、扬声器、摄像头、整机运动遥测、照片与视频采集、移动、起身收纳、预设动作和动作示教
Published Sep 11, 2026
天轶2.0 Pro — 35DOF 人形机器人 (轮式底盘 + 双臂 + 灵巧手 + 头部 + 导航)
Published Sep 11, 2026
语音感知套件 — ASR 语音识别 + TTS 语音合成 + VAD 静音检测 + 唤醒词检测
Published Sep 11, 2026
潜行科技潜鲛 P200 Pro 水下机器人:MAVLink UDP 6DOF 运动控制、解锁和状态监控
Published Sep 10, 2026
Unitree G1 — 麦克风 + 内置TTS + LED + 迎宾(greet) + 运动控制 + 手臂动作 + 状态感知
Published Sep 8, 2026
AgiBot X2 humanoid — AimDK SDK (plain rclpy) MC mode/locomotion/preset motion, per-area joint control, dexterous hand, Linkcraft dynamic motion library, camera/lidar/IMU/SLAM, TTS/emoji/LED
Published Sep 6, 2026
PNDbotics Adam — 状态感知 + 手部状态 + 持续手部控制 + 步行运动 + 手臂控制 + 3D模型
Published Sep 6, 2026
RobotEra Q5 state driver with guarded runtime-locked control cards and action-specific canvas forms
Published Sep 6, 2026
Unitree Go1 (EDU) 状态+控制驱动(原始 unitree_legged_sdk)。卡片实现聚合在 sensors.py、controllers.py、ext_devices.py 与 camera.py 四个文件中;camera.py 向 AgentCore 独立注册 camera_rgb、camera_depth、camera_pointcloud 三张五机位视觉卡,分别输出 RGB、彩色深度、XYZ 点云(点云保留 JPEG 俯视预览)。三种流在同一物理机位互斥。其余卡提供 Go1 状态、运动控制、外设和 URDF 资源;beep/speaker 与视觉 Nano 后端由容器首启自动部署。
Published Sep 6, 2026
Unitree R1-EDU — 麦克风 + TTS + LED + 运动控制 + 双目摄像头 + 状态感知
Published Sep 6, 2026
执行模型层 — VLA 策略 / 导航 / 抓取 / locomotion / 全身控制,以 processor 卡片接入
Published Sep 1, 2026
BrainCo Revo 2 灵巧手 — 6主动关节/11自由度控制、状态遥测、预设手势、LED,触觉版附带指尖触觉数据
Published Sep 1, 2026
Booster K1 — 22DOF 双足人形机器人,IMU/关节/电池/跌倒/里程计感知、相机、行走与上身关节控制、动作/起身/轨迹/音频异步任务
Published Aug 31, 2026
EngineAI T800 开发版 — speaker 音频播放、loco 安全运动、gait 步态切换、motion_recorder 录制回放、head 头部控制,以及 ROS2/Native SDK、全身状态、舞蹈/手势、虚拟手柄与 LED 控制
Published Aug 31, 2026
Lynx M20 official ROS 2/Fast DDS motion and perception interfaces, native basic_server TCP/UDP control, and Standard/Pro capability isolation
Published Aug 19, 2026
DJI Mavic 3E/3T — 飞行控制 + 相机(广角/变焦/红外) + 云台 + 航点任务 + 遥测 + 感知 + 红外测温
Published Aug 13, 2026
DJI Matrice 300 RTK — 飞行控制 + 遥测 + 感知 + HMS + 飞机信息
Published Aug 13, 2026
DJI Mavic 4E/4T — 飞行控制 + 相机 + 云台 + 航点任务 + 遥测 + 感知
Published Jul 15, 2026
What's New
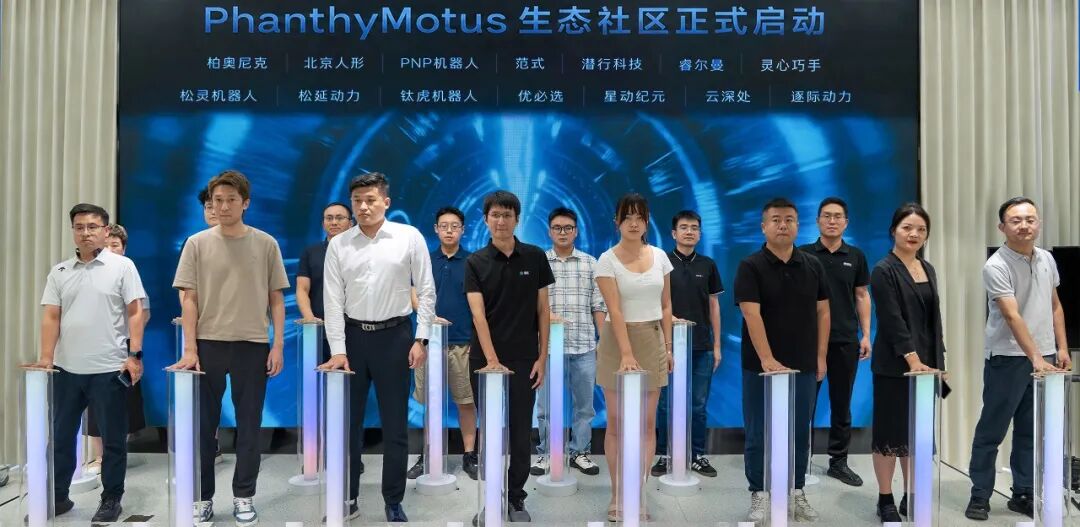
At a launch event witnessed by more than ten embodied-AI hardware makers, PhanthyMotus opened its developer incentive programme: a shared hardware pool for remote debugging and free compute tokens for contributors.
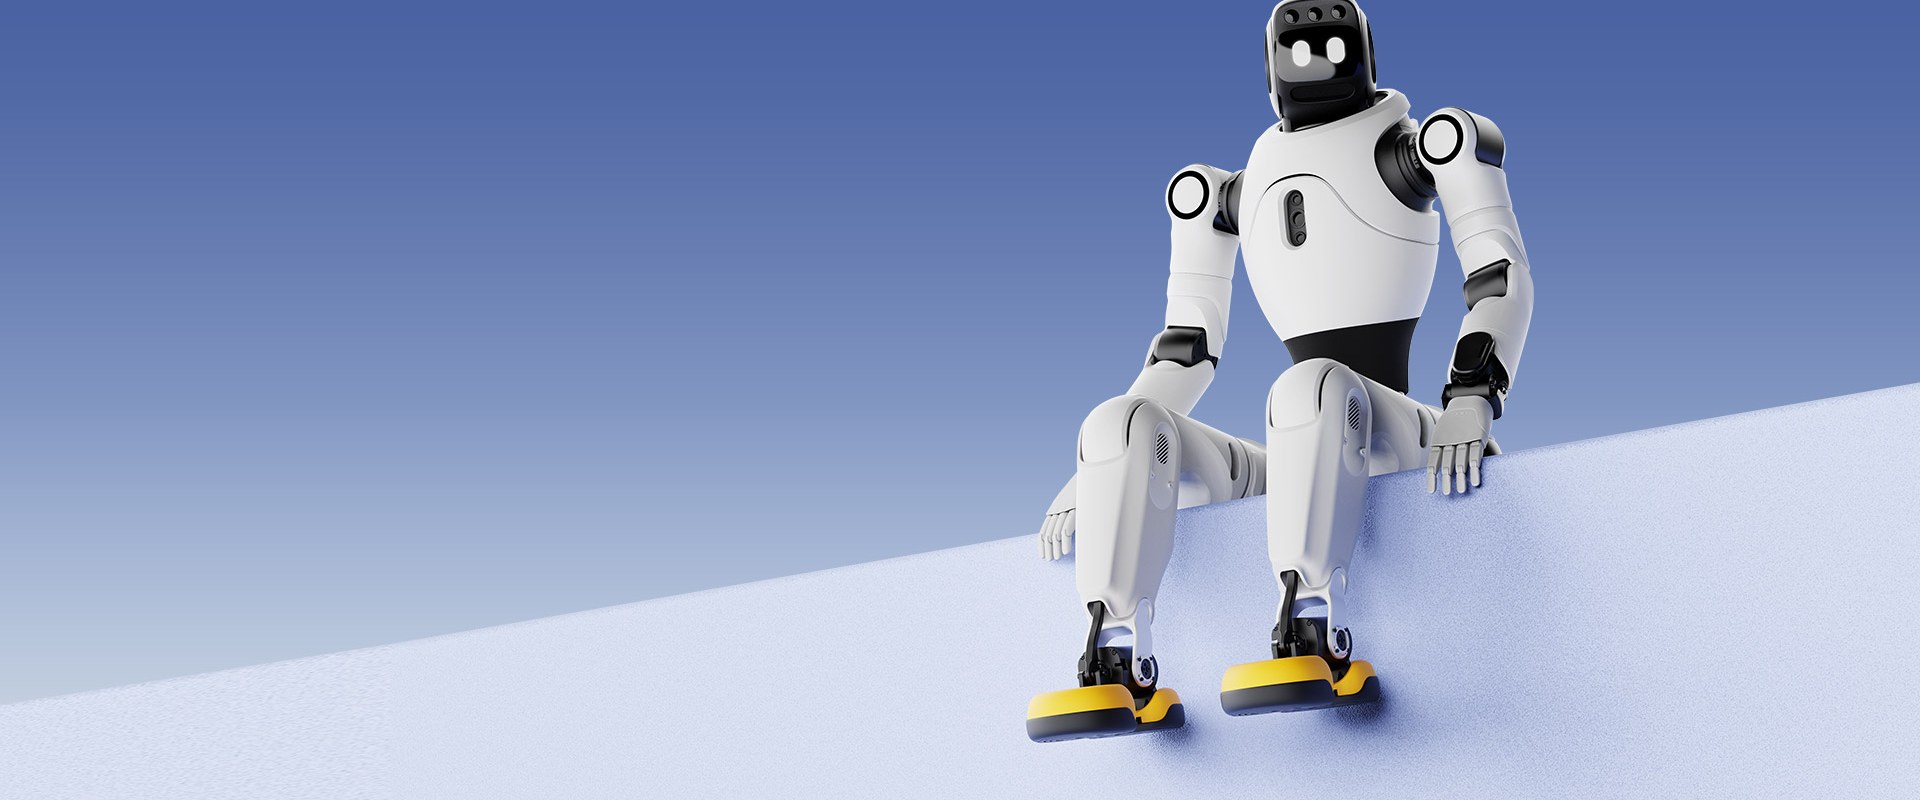
The AgiBot X2 joins the platform with 23 MCP cards — locomotion, 26 preset motions, dexterous hands, Linkcraft motion library, RGB-D + lidar + SLAM, TTS, expressions and LED.
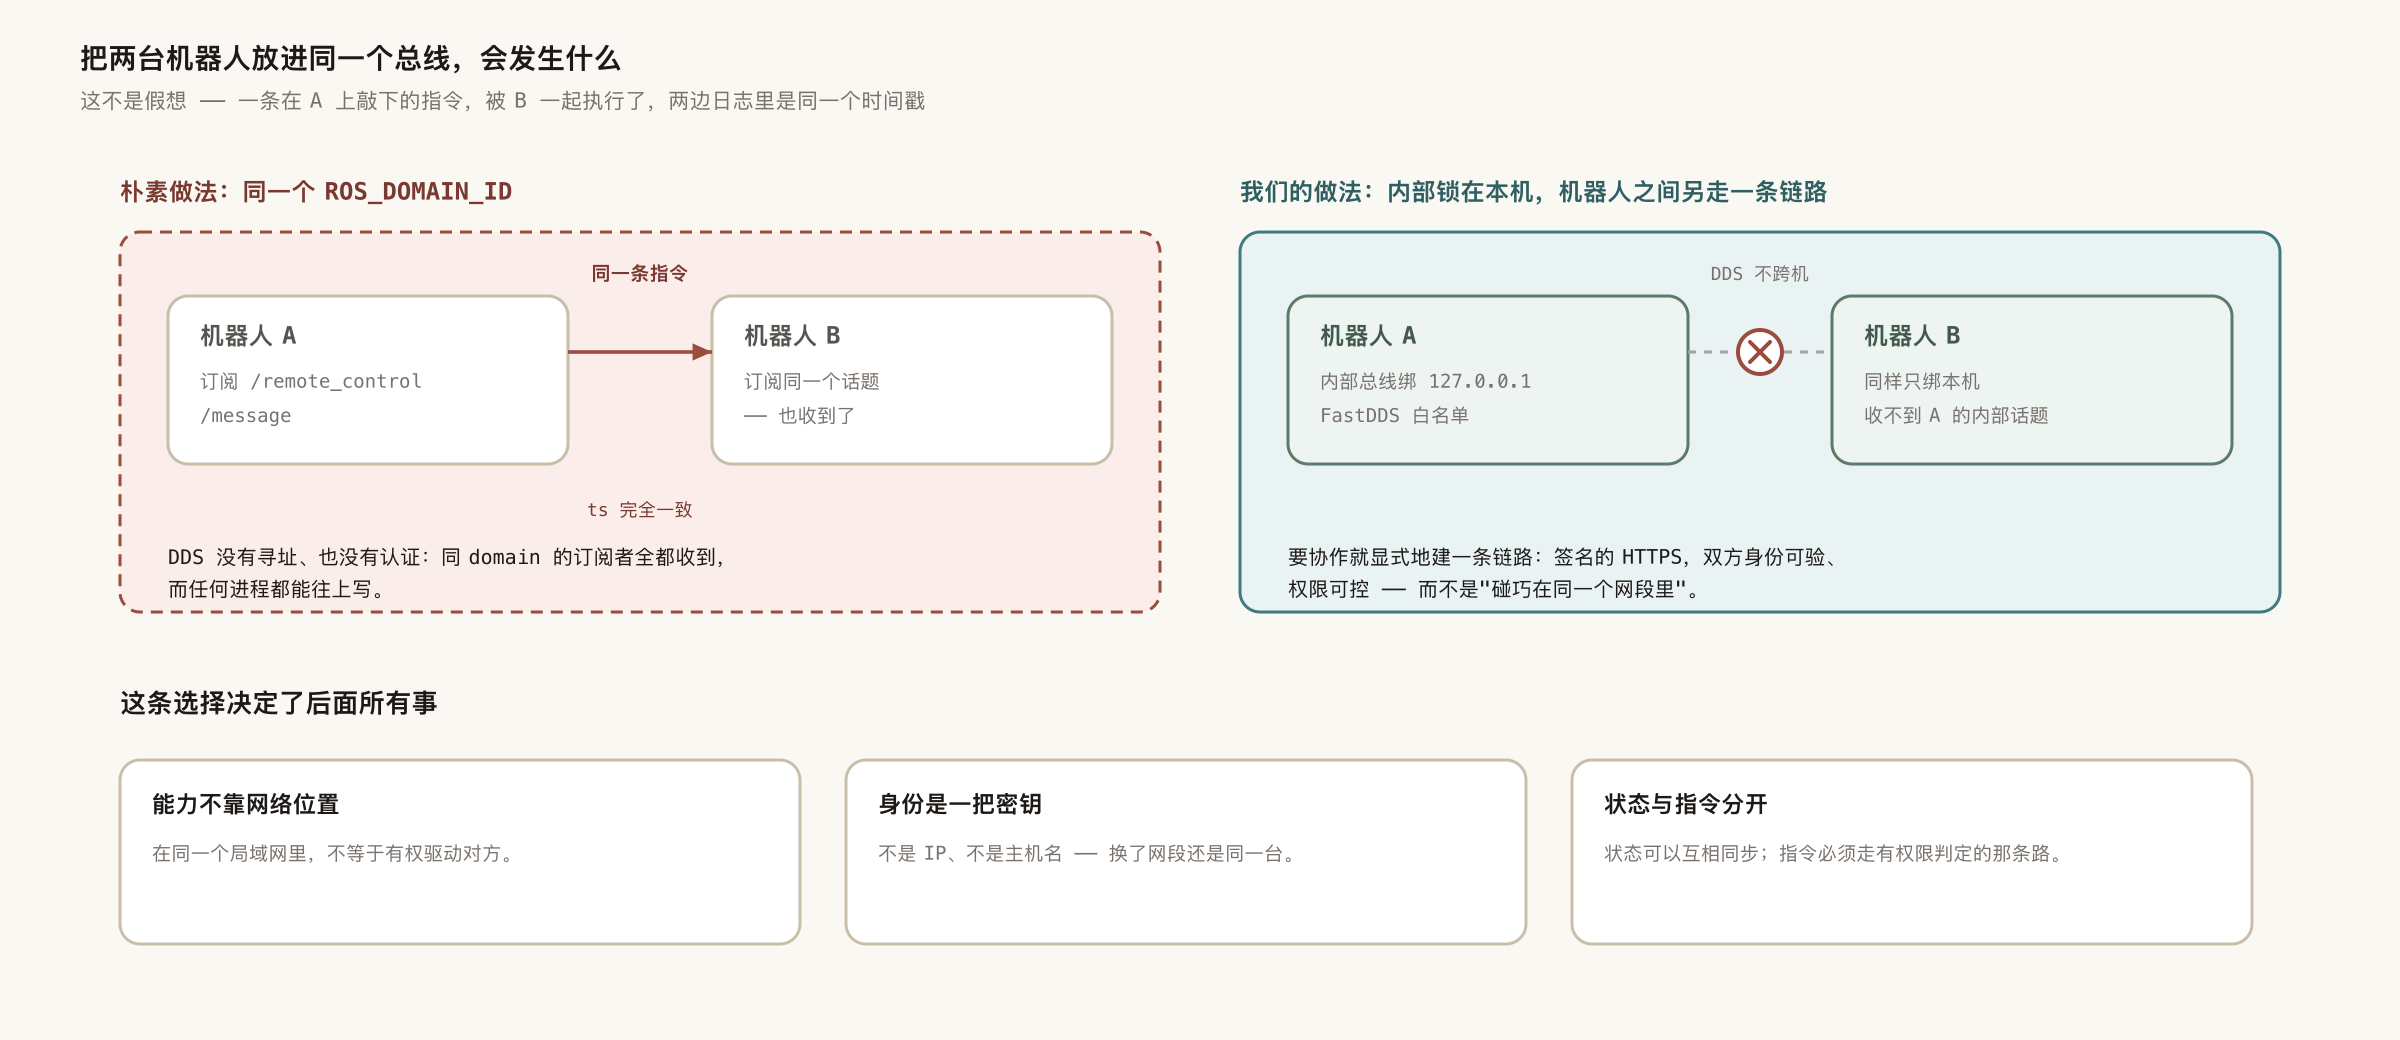
Five robots in one building and none of them knows the others exist. Putting them on one ROS domain is the obvious move and also the dangerous one: a command typed on one robot was executed by a second, same timestamp in both logs. This is the link we built instead — key-based identity, Bluetooth-style six-digit pairing, signed requests against a pinned key, and three gates before a peer can move anything. Including the scars: a keyword-based permission check that let a read-only peer drive locomotion, and a config flag that looks like a safety gate but is read by no code.
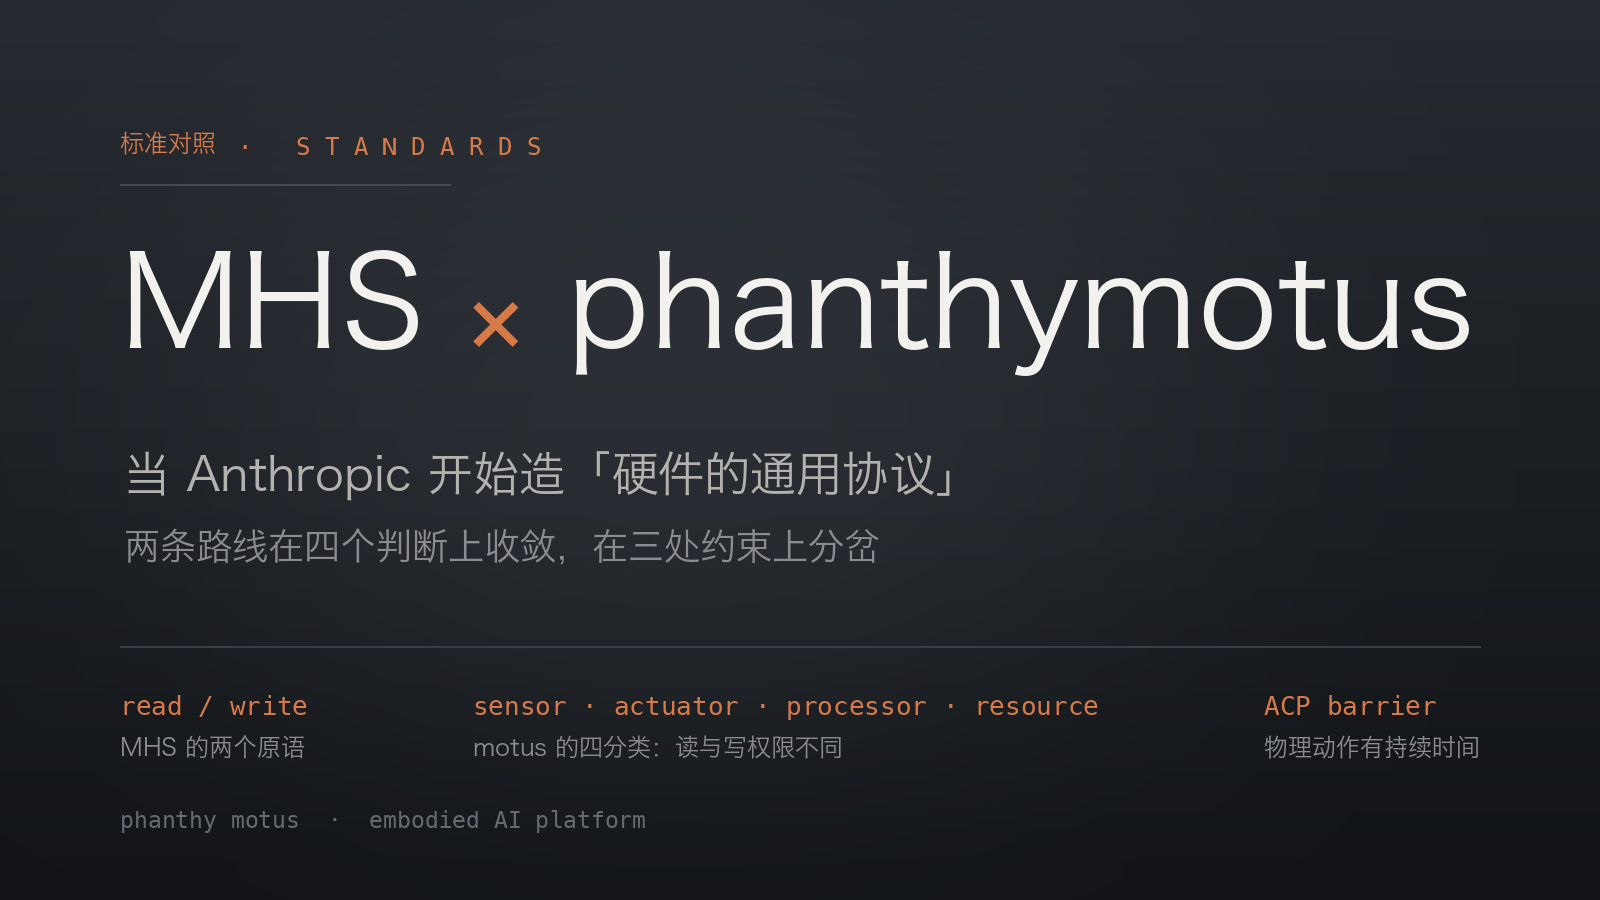
Anthropic opened a research preview of the Model Hardware Standard. Starting from a microscope rig and from a walking humanoid, two teams converged on four judgments and diverged on three constraints. A grounded comparison of the problems, the logic, and what is actually shipping.
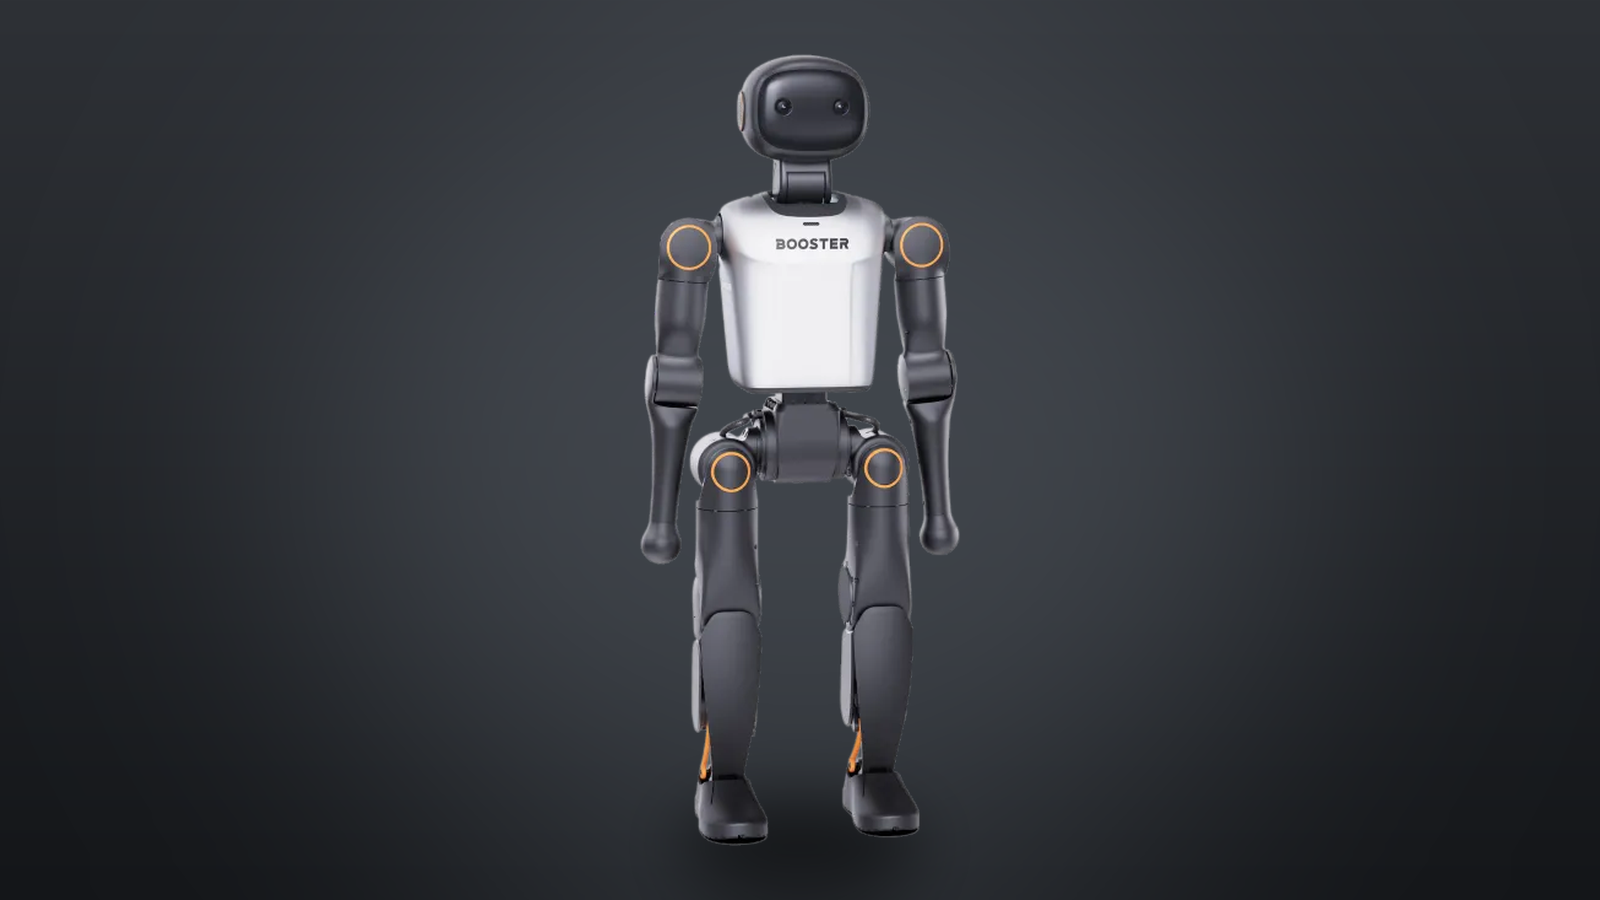
The Booster K1 bipedal humanoid now has a first-class driver: walking, gait and mode switching, head aiming, upper-body joint control, preset actions, get-up, trajectory playback, audio and vision — all as tools your agent can call.
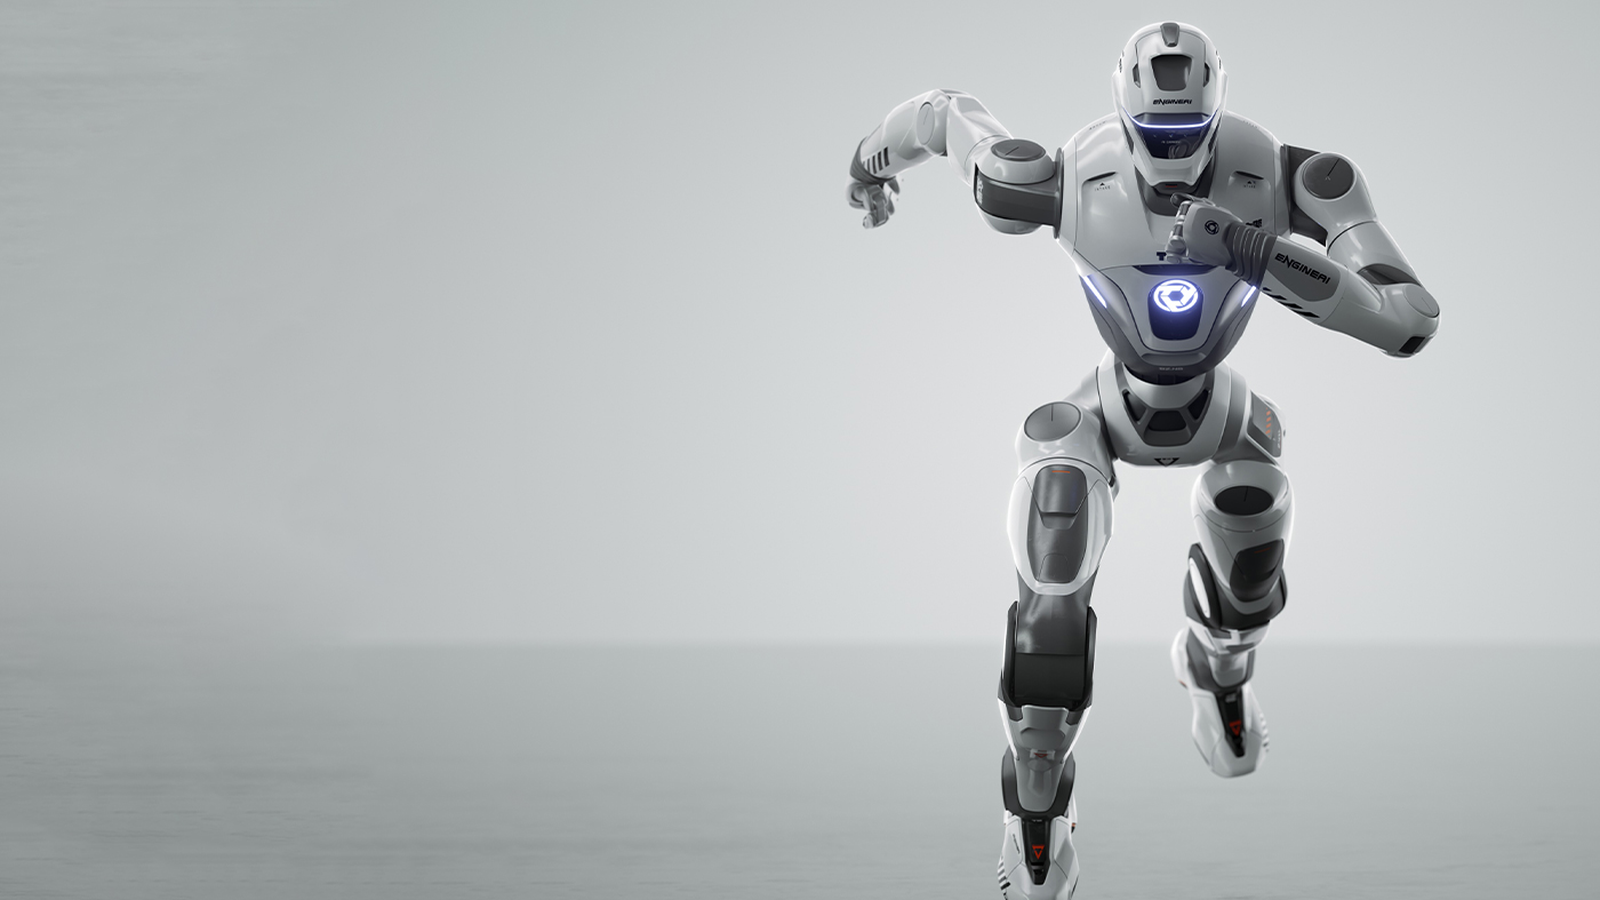
The EngineAI T800 driver grows a speaker, walking with real gaits, a motion recorder, and a posture switch that always routes through standing — plus honest state reporting instead of guesses.