G1 gets up from a squat again — and reports the posture it is really in
A G1 that squatted could not stand back up: the stand-up call reported "robot is on ground" and bounced between states. Fixed on the real robot, along with the deeper confusion between control mode and physical posture.
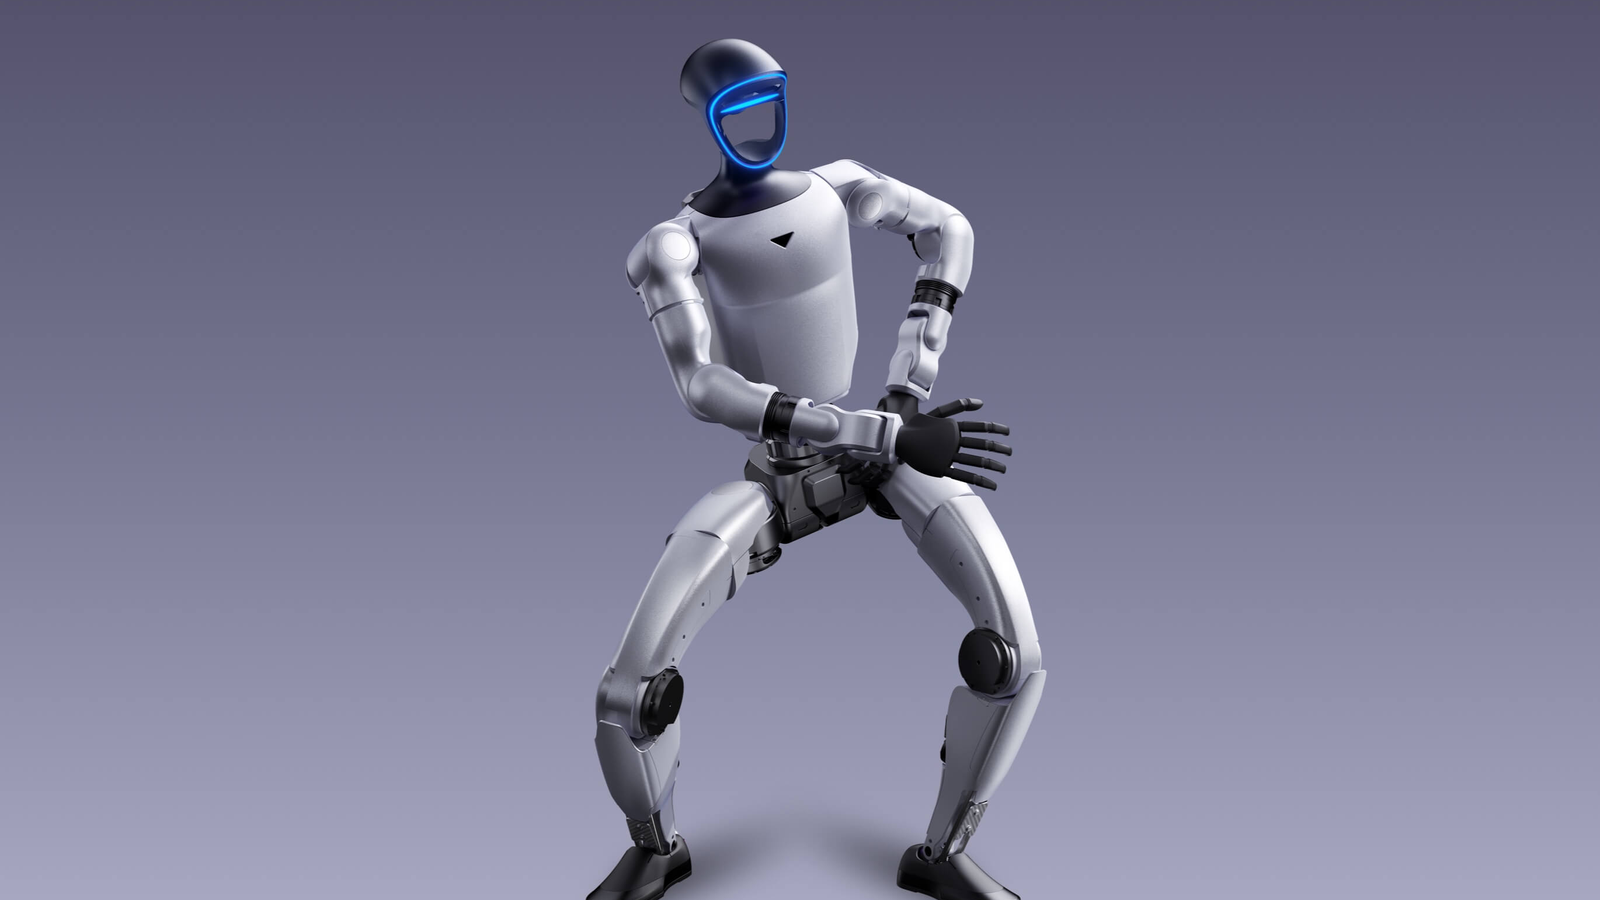
Squatting was a one-way trip
Ask a G1 to squat, then ask it to stand: the stand-up call failed with "robot is on ground", the lie-to-stand call failed too, and the robot bounced between states without moving. This release fixes it on the real machine.
What was wrong
- The wait watched the wrong signal. Standing up polled for a target state the SDK never sets, so a transition the robot had already physically finished was reported as a timeout.
- Control mode was being confused with body posture. Under zero-torque or damping the robot goes soft, and to the state machine "lying flat" and "folded into a squat" look identical — so the driver could not tell where the body actually was.
What you get
- Squat and stand both work, because they use the balanced squat/stand transition the way the SDK intends, while getting up from lying down uses its own dedicated transition.
- Posture is derived from the joints, not guessed from a mode — standing, squatting and lying down are reported from the actual joint angles.
- Damping and zero-torque stopped pretending to be motions. They are control modes, and they now appear as control modes instead of masquerading as posture changes.
How to try it
Update the Unitree G1 driver from the console and ask the agent to squat and stand. The posture reported on the dashboard should follow the body, not the mode.
Getting up must pass through damping — that is the vendor's own procedure, and the driver follows it. Stand clear of the robot for every squat and stand-up: it is a full-body move that shifts the machine's balance.