Releasedriver2026-08-28
Q5 can turn at the waist, and its gestures stopped stuttering
The RobotEra Q5 driver adds waist rotation as a first-class control, and fixes the arm gestures: no more mirrored high-five, no more jerky motion, and a reset that brings both arms home together.
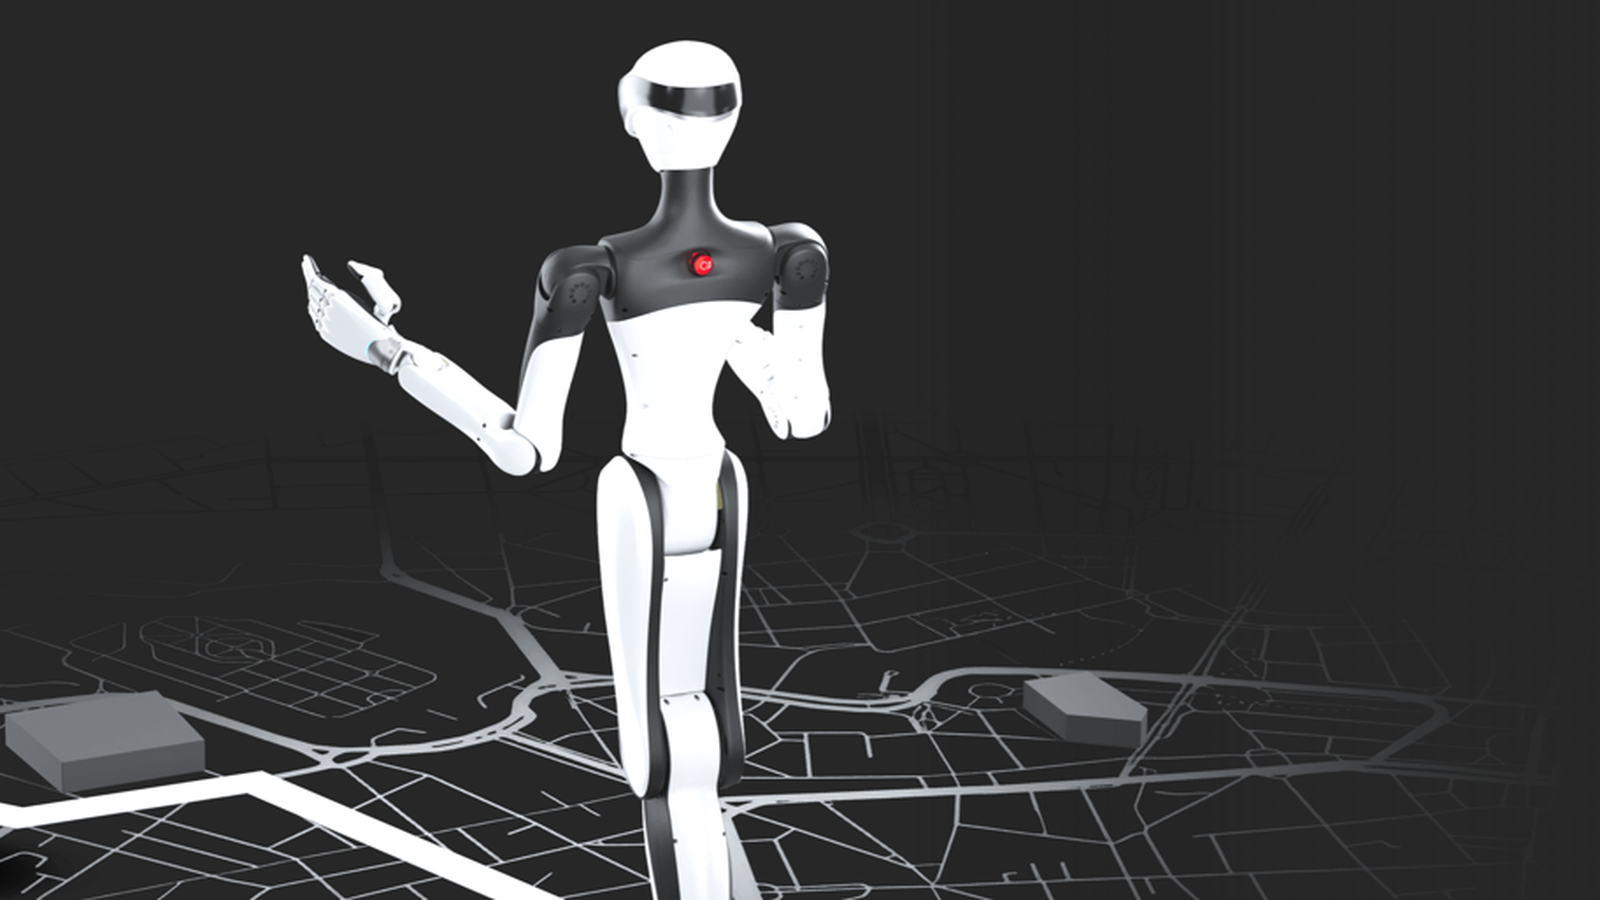
Facing the person you are talking to
A robot on a mobile base has to drive itself around just to face someone standing beside it. Q5 can now turn at the waist instead — and while we were in there, the arm gestures got the polish they were missing.
What you get
- Waist rotation as a direct control. Give the waist an absolute angle and it turns to it, exactly the way head aiming already works. Turning to face someone no longer means moving the whole base.
- Gestures that look intentional. Interpolated positions are now published as a batch, which removes the stutter that made every gesture look like it was fighting itself.
- High-five is symmetric again. A mirroring bug made the left and right arms disagree; both the shoulder direction and the wrist mirroring are corrected.
- Reset brings both arms home at once, smoothly interpolating to zero instead of one arm after the other.
- Commands stop drowning each other. The publish rate now matches what the vendor's controller expects, so the command topic is no longer flooded.
- Available gestures: salute, welcome, raise, shake hands, high five.
How to try it
Update the RobotEra Q5 driver from the console, then drop the waist and arm gesture cards onto the canvas. Ask the agent to turn towards someone and wave.
Waist rotation and arm gestures both swing mass at human head height. Keep people out of the arms' reach before triggering a gesture.
Contributed by a community developer.