Underwater: the CHASING Qianjiao P200 Pro ROV
The platform's first underwater robot arrives with six cards: attitude/depth/position, status, battery, IMU, a live RTSP camera and six-degree-of-freedom motion control. MAVLink over UDP, with a one-second heartbeat that refuses to move if the link has been quiet for three seconds.
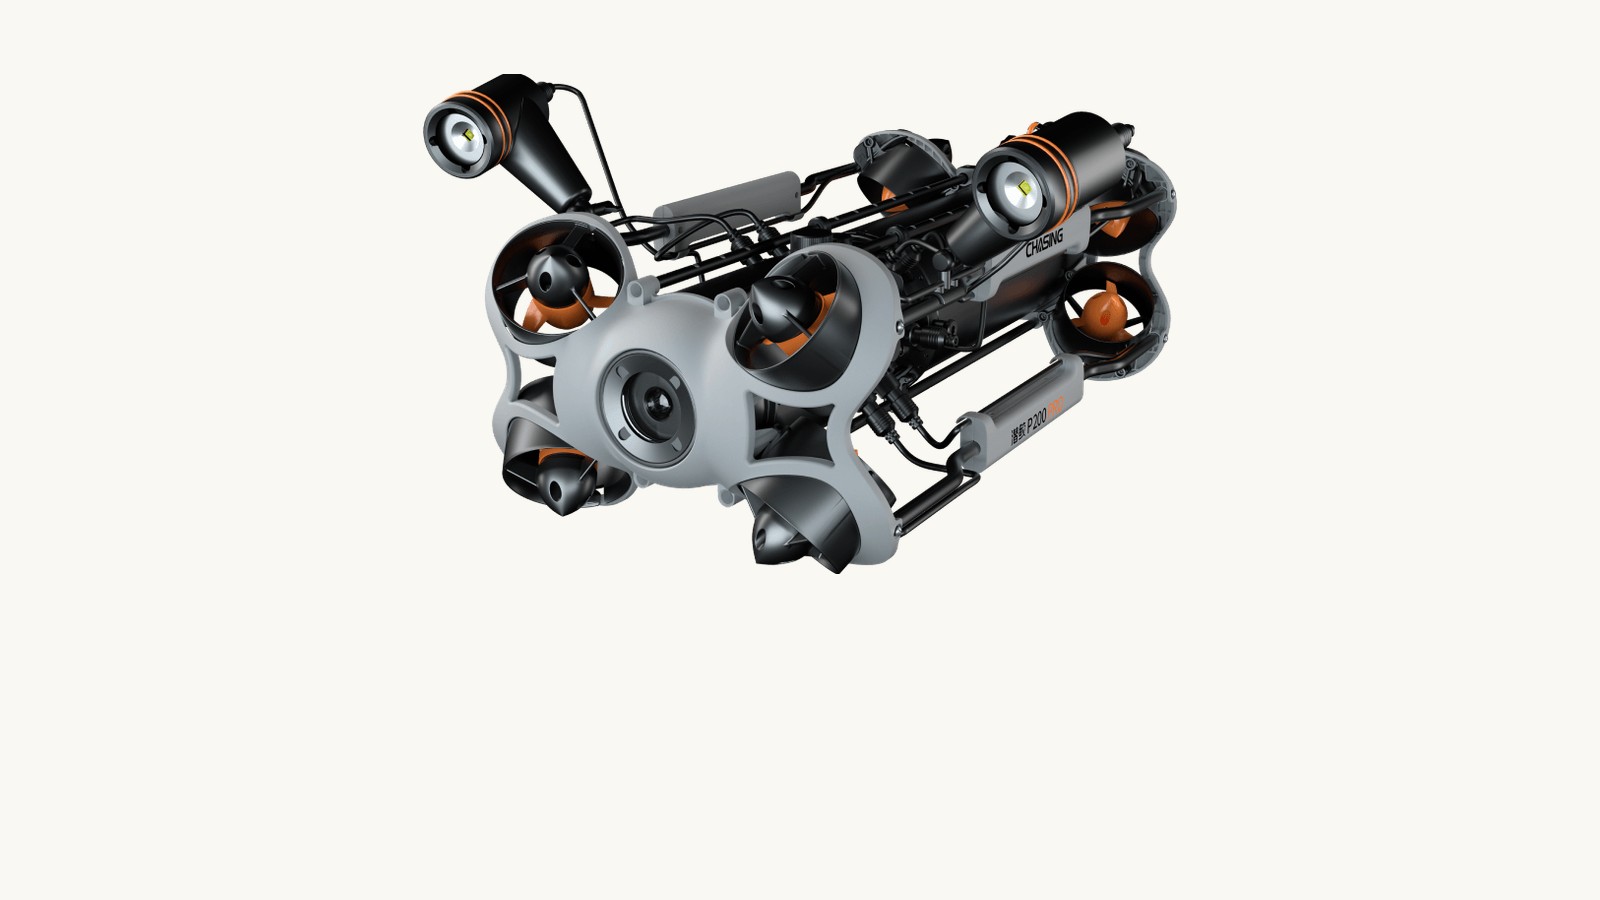
The platform gains its first underwater robot: the CHASING Qianjiao P200 Pro ROV.
What it can do
Six cards — five to read, one to act.
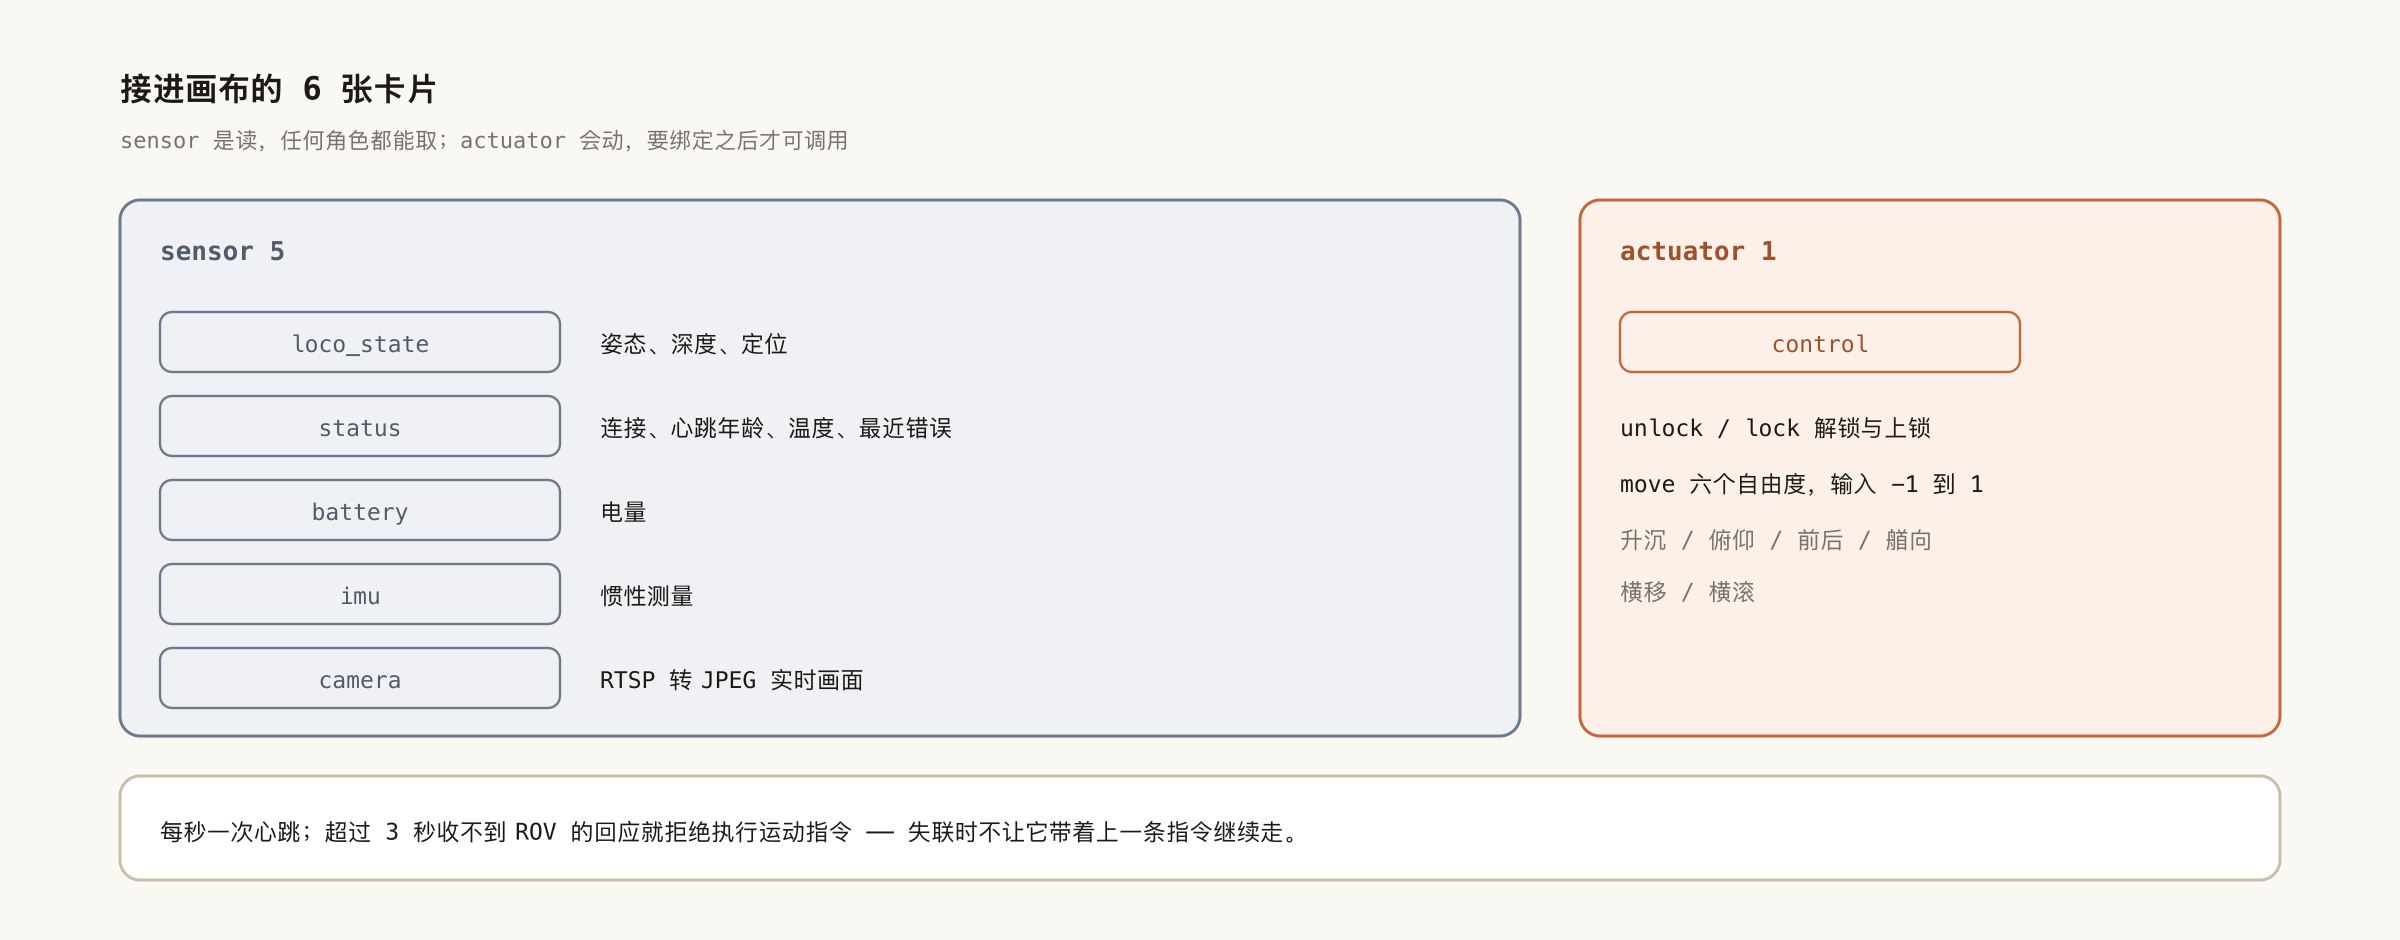
status is the one to check first: connection state, how stale the heartbeat is, hull temperature, video proxy state and the most recent error. loco_state gives attitude, depth and position; battery gives charge; imu gives inertial data; camera converts the vehicle's RTSP stream to JPEG for the canvas.
control is the only card that moves anything: unlock / lock, and move across six degrees of freedom — heave, pitch, forward, yaw, lateral and roll, each taking an input from -1 to 1.
It stops when the link drops
The driver sends a heartbeat to the ROV once a second. If no reply arrives for more than 3 seconds, motion commands are refused. The last thing you want underwater is a vehicle carrying on with its previous command after the link is gone.
Communication is MAVLink over UDP, as specified by the vendor; the vehicle link does not go through DDS.
Before deploying
Verify the UDP link with QGroundControl first, and confirm that unlock and link-loss protection behave as expected, before wiring it into the platform. With no hardware at hand, mock mode lets you build out the canvas.
The camera uses the device's factory account by default; if the password has been changed, override it with an environment variable — it never appears in any response.