EngineAI T800 sees in 3D and knows how far it has walked
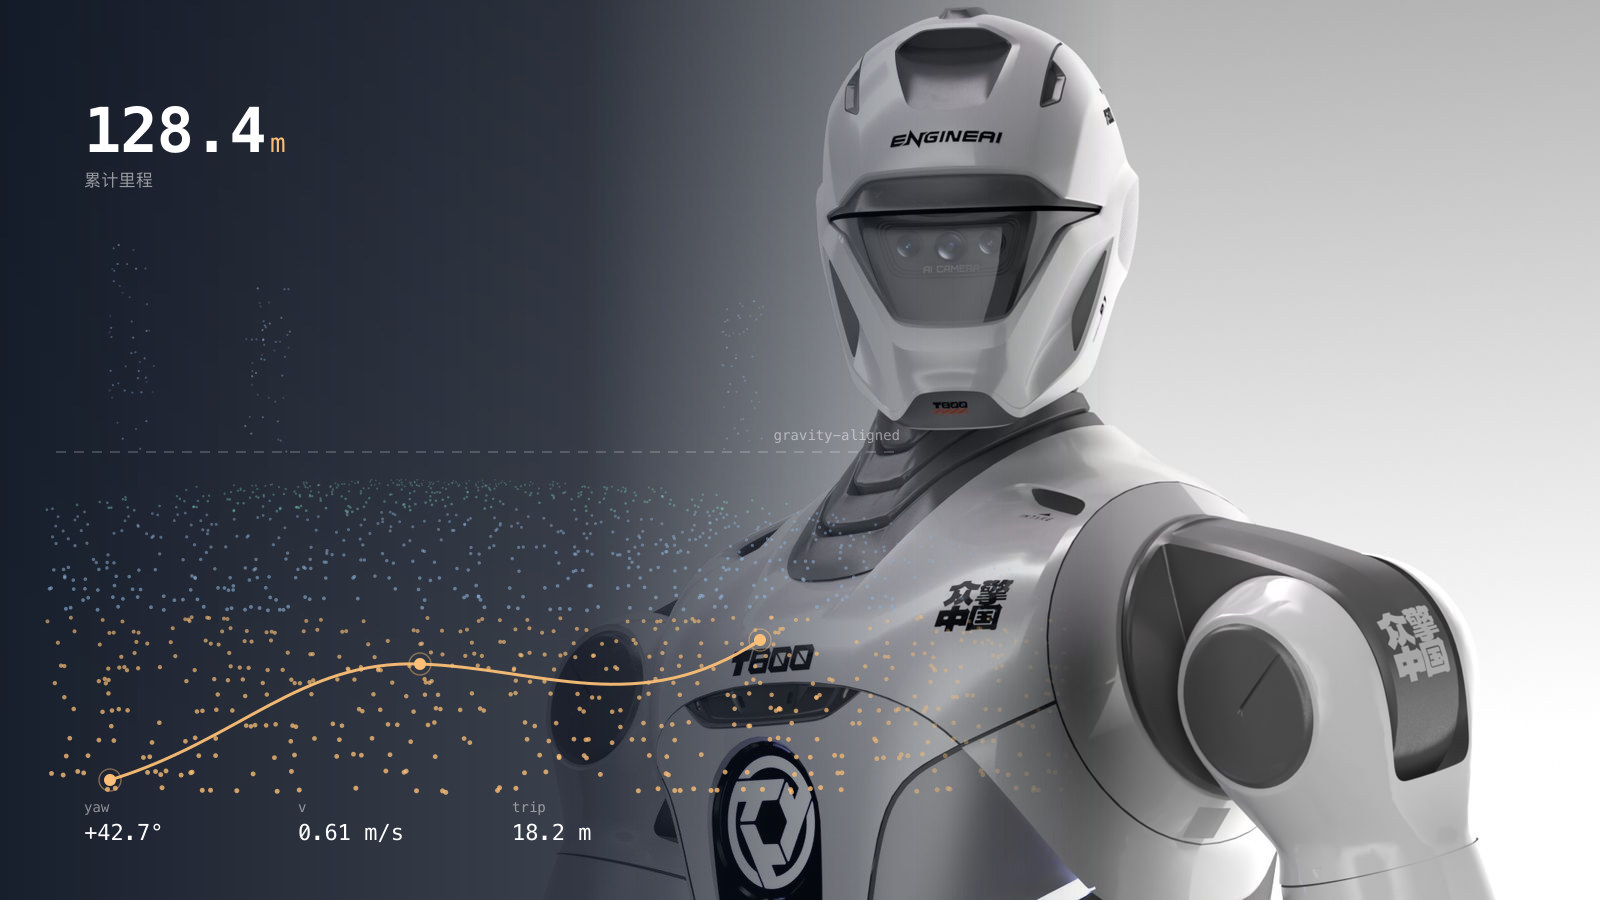
The T800's point cloud card is now complete and usable, showing the three-dimensional space in front of it live on the dashboard. It defaults to a gravity-aligned frame, so the view is no longer tilted by the sensor's mounting angle. A new odometry card reports position, heading, speed, total distance travelled, and whether the robot is moving or still.
Three-dimensional space you can see
The T800's point cloud card is now complete and usable — start and stop, switching data source, and live rendering on the dashboard all work end to end.
It defaults to a gravity-aligned frame. The sensor is mounted at a downward angle, and in its raw frame the whole view is tilted — the floor is not level, walls are not vertical, and it looks as though the robot cannot stand up straight. Aligned, the horizon is horizontal. The raw source is still available at any time.
It knows how far it has walked
A new read-only odometry card (it takes no part in any control loop) reports:
| Where | Position, heading |
| How fast | Linear velocity, angular velocity, planar speed |
| How far | Total distance, distance this trip |
| State | Moving or still, and how long it has been still |
It also carries a set of data-health counters: how many messages arrived, how many were valid, how many jumps and bad timestamps were rejected. When something is off, those numbers say it is a data problem first — instead of leaving someone to guess why the robot appears to be drifting.
Also
After a system upgrade, the low-level services behind the vision path can be rebuilt with a single command, reading the current device calibration automatically rather than needing to be reconfigured by hand.