LimX TRON2 joins the platform — see both arms, and reset them with one call
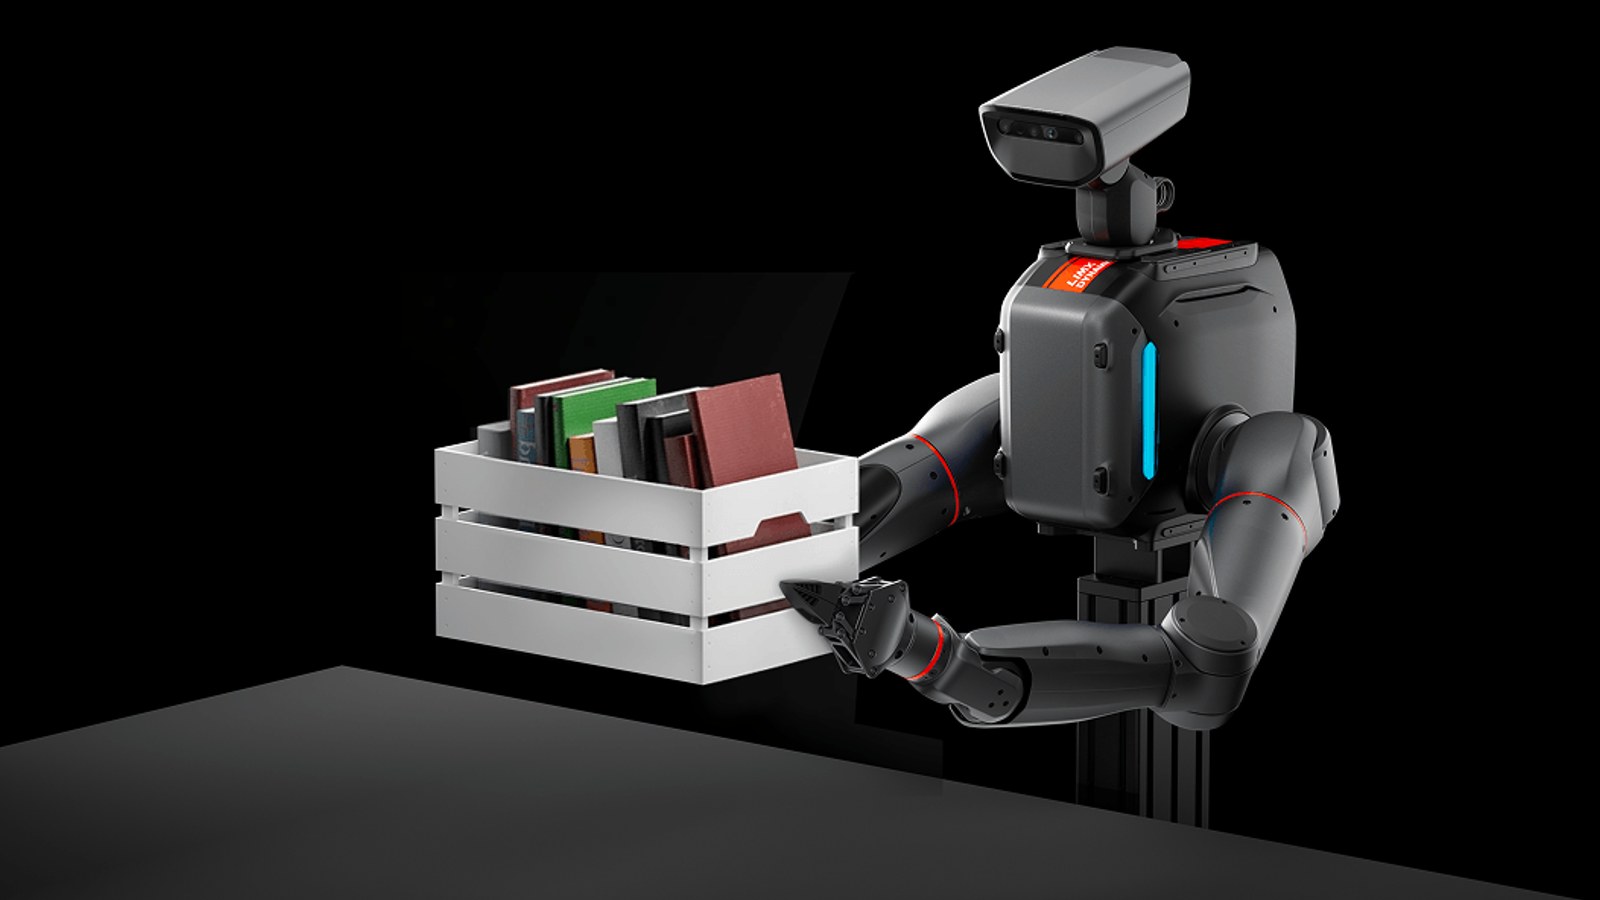
The LimX Dynamics TRON2 dual-arm robot is now supported: the real pose of all 16 motors rendered as a skeleton from the vendor’s own URDF, three on-demand camera feeds (head, left wrist, right wrist), joint-target control of both arms, and a one-call reset to the arms-down pose.
Cards
joint_state renders the real pose of both arms and the head from the vendor’s own URDF, keeping the original 16-motor mapping and kinematics. camera, camera_left and camera_right are the head and both wrist feeds — started and stopped on demand, rate-limited, read-only. arm_control moves both arms to joint targets and resets them to the natural arms-down pose stored on the robot itself.
The grippers are drawn, not driven
Eight fixed display nodes at each gripper mount let the skeleton show a two-finger outline that follows the corresponding wrist. It is a fixed, closed shape at a fixed size — a schematic. It does not report real grasp state, the driver does not control the grippers, and no synthetic open/close feedback is published. Showing a gripper that moves when nothing is moving is worse than showing none.
A long motion reports completion when it is done, so the model does not have to poll.