


Driver· x-humanoidtianyi2.0
X-humanoid Tianyi 2.0 Pro Bundle
天轶2.0 Pro — 35DOF 人形机器人 (轮式底盘 + 双臂 + 灵巧手 + 头部 + 导航)
Requiresarm64
+108
Published Sep 16, 2026
PhanthyMotus is a next-generation, open-source framework and platform for Embodied AI Agents. Built upon a robust ROS2 foundation, it seamlessly bridges diverse sensor inputs with advanced robot execution. By enabling flexible integration of World Models, LLMs, and VLMs, PhanthyMotus transforms traditional hardware into soulful, intelligent assistants capable of perceiving, thinking, and acting independently in the real world.
A Unified Embodied Agent Platform
Dozens of robot brands supported — humanoids, quadrupeds, wheeled, drones, arms, and underwater vehicles
Why PhanthyMotus
Drop the remote control. PhanthyMotus enables robots to understand their environment, plan actions, and execute tasks autonomously — truly becoming intelligent assistants in everyday life.
Production-Ready ROS2 Core
Native compatibility with mainstream robotic hardware ecosystems
Modular & Extensible Architecture
Plug in custom perception and decision-making models effortlessly
User-Centric Autonomy
Robots autonomously complete real-world tasks
Pluggable Multi-Model Framework
Flexible integration of World Models, LLMs, and VLMs
Full-Stack Agent Architecture
Long-term memory, dynamic skill library, continuous Agent Loop
Unified Sensor & Actuator Interface
Multi-sensor fusion and precise motor control
Hardware Scalability
Humanoids, quadrupeds, robotic arms, wheeled platforms, drones
Skill Scalability
Continuously train, import, and stack new skills
AI Model Scalability
Seamlessly upgrade to the latest perception and decision models
Zero-Config Discovery
Peers find each other over LAN, offline mesh, or across sites
Shared Peer Capabilities
A peer's sensors and actuators become your agent's tools
Short-Code Pairing Security
Key-based identity, six-digit pairing on both sides, roles that default to read-only
Architecture
Peer Mesh & Security
Platform Preview
Add sensors and actuators onto the canvas, connect them to the Agent Loop — the framework handles data flow and execution automatically, like building blocks
Audio waveforms, battery status, 3D skeleton and point cloud visualization
Identity setup, system prompt, and long-term memory editing online
Deploy and manage Agent Core and hardware driver containers
All Resources · 22 available · 344 cards
Production-grade images, reviewed and ARM64 ready.
天轶2.0 Pro — 35DOF 人形机器人 (轮式底盘 + 双臂 + 灵巧手 + 头部 + 导航)
Published Sep 16, 2026
Unitree As2W — 轮足运动、特技、SLAM 空间动作、状态感知与雷达
Published Sep 16, 2026
执行模型层 — VLA 策略 / 导航 / 抓取 / locomotion / 全身控制,以 processor 卡片接入
Published Sep 16, 2026
Published Sep 16, 2026
感知套件 — 语音:ASR 语音识别 + TTS 语音合成 + VAD 静音检测 + 唤醒词检测;视觉:物体检测 + 单目深度 + OCR 文字识别 + 人脸识别。视觉与本地语音模型跑 TensorRT
Published Sep 16, 2026
Unitree G1 — 麦克风 + 内置TTS + LED + 运动控制 + 手臂动作 + 状态感知 + 拍照/录像采集
Published Sep 15, 2026
Unitree Go2 — 运动控制 + 避障 + 语音 + 视频 + 拍照/录像采集 + RealSense 深度/红外 + 导航 + 遥控器接管监控
Published Sep 15, 2026
ARM64 RealMan RM75-6F-V state, joint motion, two-finger gripper, and upper-computer RealSense camera Driver
Published Sep 11, 2026
Noetix Bumi-EDU — 麦克风、扬声器、摄像头、整机运动遥测、照片与视频采集、移动、起身收纳、预设动作和动作示教
Published Sep 11, 2026
潜行科技潜鲛 P200 Pro 水下机器人:MAVLink UDP 6DOF 运动控制、解锁和状态监控
Published Sep 10, 2026
AgiBot X2 humanoid — AimDK SDK (plain rclpy) MC mode/locomotion/preset motion, per-area joint control, dexterous hand, Linkcraft dynamic motion library, camera/lidar/IMU/SLAM, TTS/emoji/LED
Published Sep 6, 2026
PNDbotics Adam — 状态感知 + 手部状态 + 持续手部控制 + 步行运动 + 手臂控制 + 3D模型
Published Sep 6, 2026
RobotEra Q5 state driver with guarded runtime-locked control cards and action-specific canvas forms
Published Sep 6, 2026
Unitree Go1 (EDU) 状态+控制驱动(原始 unitree_legged_sdk)。卡片实现聚合在 sensors.py、controllers.py、ext_devices.py 与 camera.py 四个文件中;camera.py 向 AgentCore 独立注册 camera_rgb、camera_depth、camera_pointcloud 三张五机位视觉卡,分别输出 RGB、彩色深度、XYZ 点云(点云保留 JPEG 俯视预览)。三种流在同一物理机位互斥。其余卡提供 Go1 状态、运动控制、外设和 URDF 资源;beep/speaker 与视觉 Nano 后端由容器首启自动部署。
Published Sep 6, 2026
Unitree R1-EDU — 麦克风 + TTS + LED + 运动控制 + 双目摄像头 + 状态感知
Published Sep 6, 2026
BrainCo Revo 2 灵巧手 — 6主动关节/11自由度控制、状态遥测、预设手势、LED,触觉版附带指尖触觉数据
Published Sep 1, 2026
Booster K1 — 22DOF 双足人形机器人,IMU/关节/电池/跌倒/里程计感知、相机、行走与上身关节控制、动作/起身/轨迹/音频异步任务
Published Aug 31, 2026
EngineAI T800 开发版 — speaker 音频播放、loco 安全运动、gait 步态切换、motion_recorder 录制回放、head 头部控制,以及 ROS2/Native SDK、全身状态、舞蹈/手势、虚拟手柄与 LED 控制
Published Aug 31, 2026
Lynx M20 official ROS 2/Fast DDS motion and perception interfaces, native basic_server TCP/UDP control, and Standard/Pro capability isolation
Published Aug 19, 2026
DJI Mavic 3E/3T — 飞行控制 + 相机(广角/变焦/红外) + 云台 + 航点任务 + 遥测 + 感知 + 红外测温
Published Aug 13, 2026
DJI Matrice 300 RTK — 飞行控制 + 遥测 + 感知 + HMS + 飞机信息
Published Aug 13, 2026
DJI Mavic 4E/4T — 飞行控制 + 相机 + 云台 + 航点任务 + 遥测 + 感知
Published Jul 15, 2026
What's New
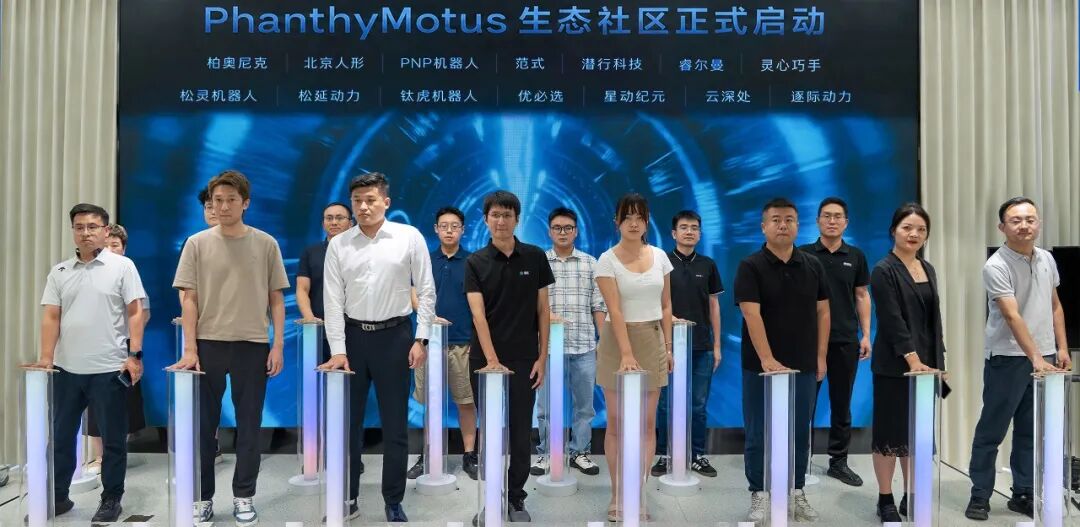
At a launch event witnessed by more than ten embodied-AI hardware makers, PhanthyMotus opened its developer incentive programme: a shared hardware pool for remote debugging and free compute tokens for contributors.
Object recognition runs TensorRT directly on YOLOE-26s: 31.9 → 19.8 ms per frame on an Orin 5, accuracy from LVIS 24.4 to 30.8. A new visual_depth card estimates depth from an ordinary camera — in metres, not a relative scale — and a tape measure against a flat wall calibrates it to your own camera. Vision cards also answer about a single photo or URL with no camera attached.
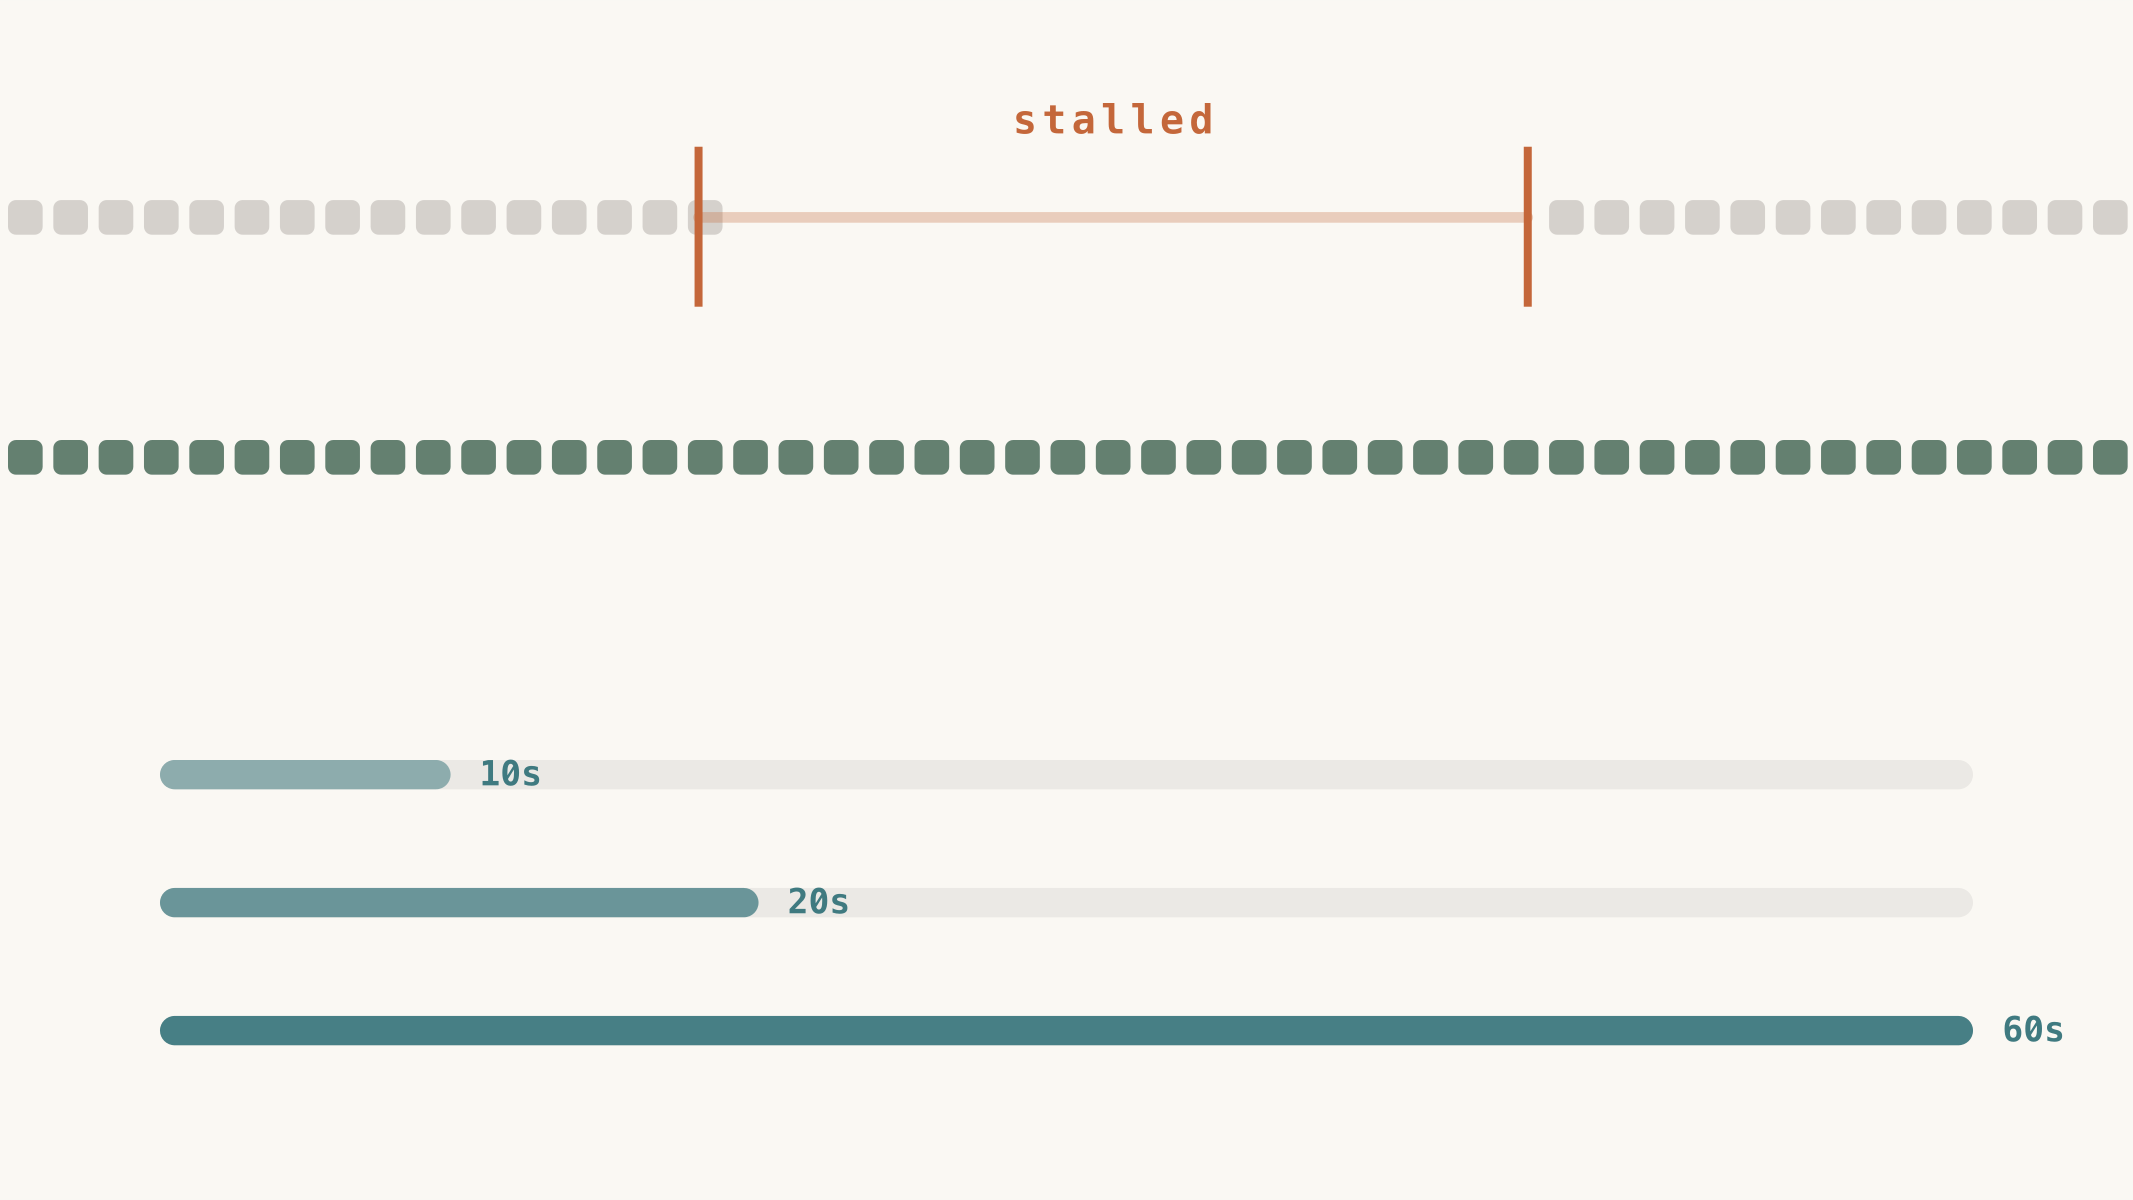
LLM calls are streamed, so a stuck connection and a long answer are finally distinguishable. Liveness is judged on time-to-first-token (10/20/60 s, rising per retry) and the gap between tokens, cutting the worst case from six minutes to 90 seconds — while the total budget actually loosens to 600 s so long answers are no longer killed by mistake.
Results are now parsed by their own type. Image search actually returns image URLs (they used to be dropped entirely), video results carry duration, resolution and cover, and WebFetch can save to disk — which completes the search → download → send chain that used to break on the last metre.
Progress narration moves from "the model volunteers a sentence" to a framework guarantee: past a threshold of silent rounds or seconds, it generates a short spoken progress line. It skips when there is genuinely nothing new, and immersive skills can ask for quiet.
High-priority input now wakes the agent out of a wait on an unrelated running action — a "stop talking" said mid-narration used to sit for up to 58 seconds. Narration itself also queues instead of cutting in. Subagent round budgets rise from a hardcoded 10 to a configurable 50, and running out now writes up what it found instead of discarding it.