What's New
Latest Updates
English transcription holds up in noise
A new parakeet-en model trained on ~1.7M hours of diverse audio — deliberately including non-speech material to suppress hallucination — replaces an audiobook-trained option that was a poor match for a robot microphone. Punctuation and casing included, 104 MB, RTF 0.039 on CPU.
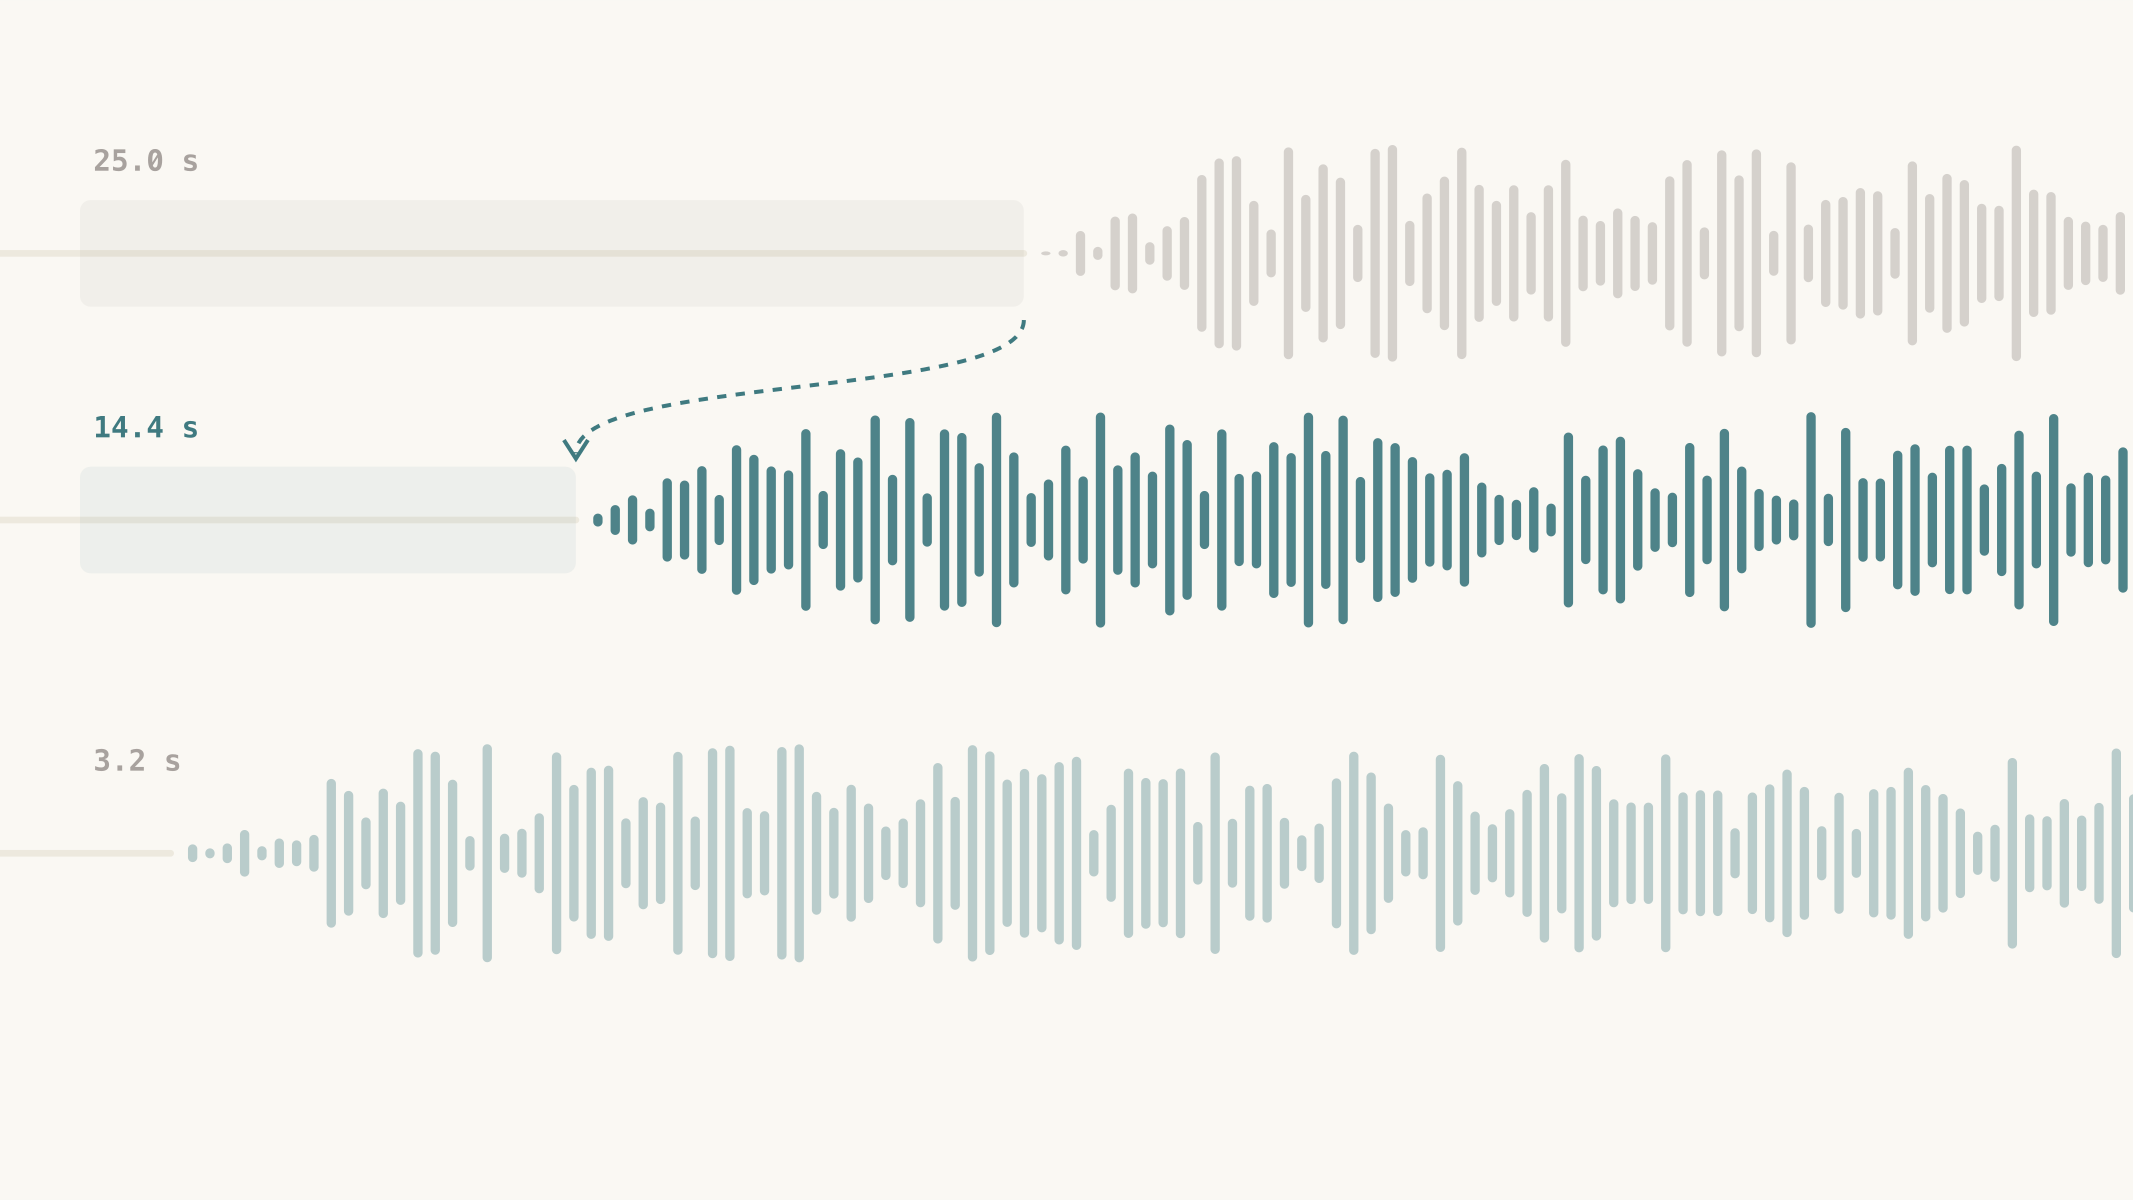
Japanese speech starts talking sooner
Japanese synthesis now streams instead of waiting for the whole utterance. On CPU a 26-second sentence starts after 14.4 seconds instead of 25; on GPU it runs at RTF 0.069. The move also removes a hazard that could kill the entire perception process on JetPack 5.11.
Adam's state is visible, and it can be stopped
The PNDbotics Adam gains three read-only telemetry cards — per-joint motor state, whole-robot state, and 12-channel feedback per hand at 50 Hz — plus an emergency stop. Its communication interface is now configurable for wired sites.
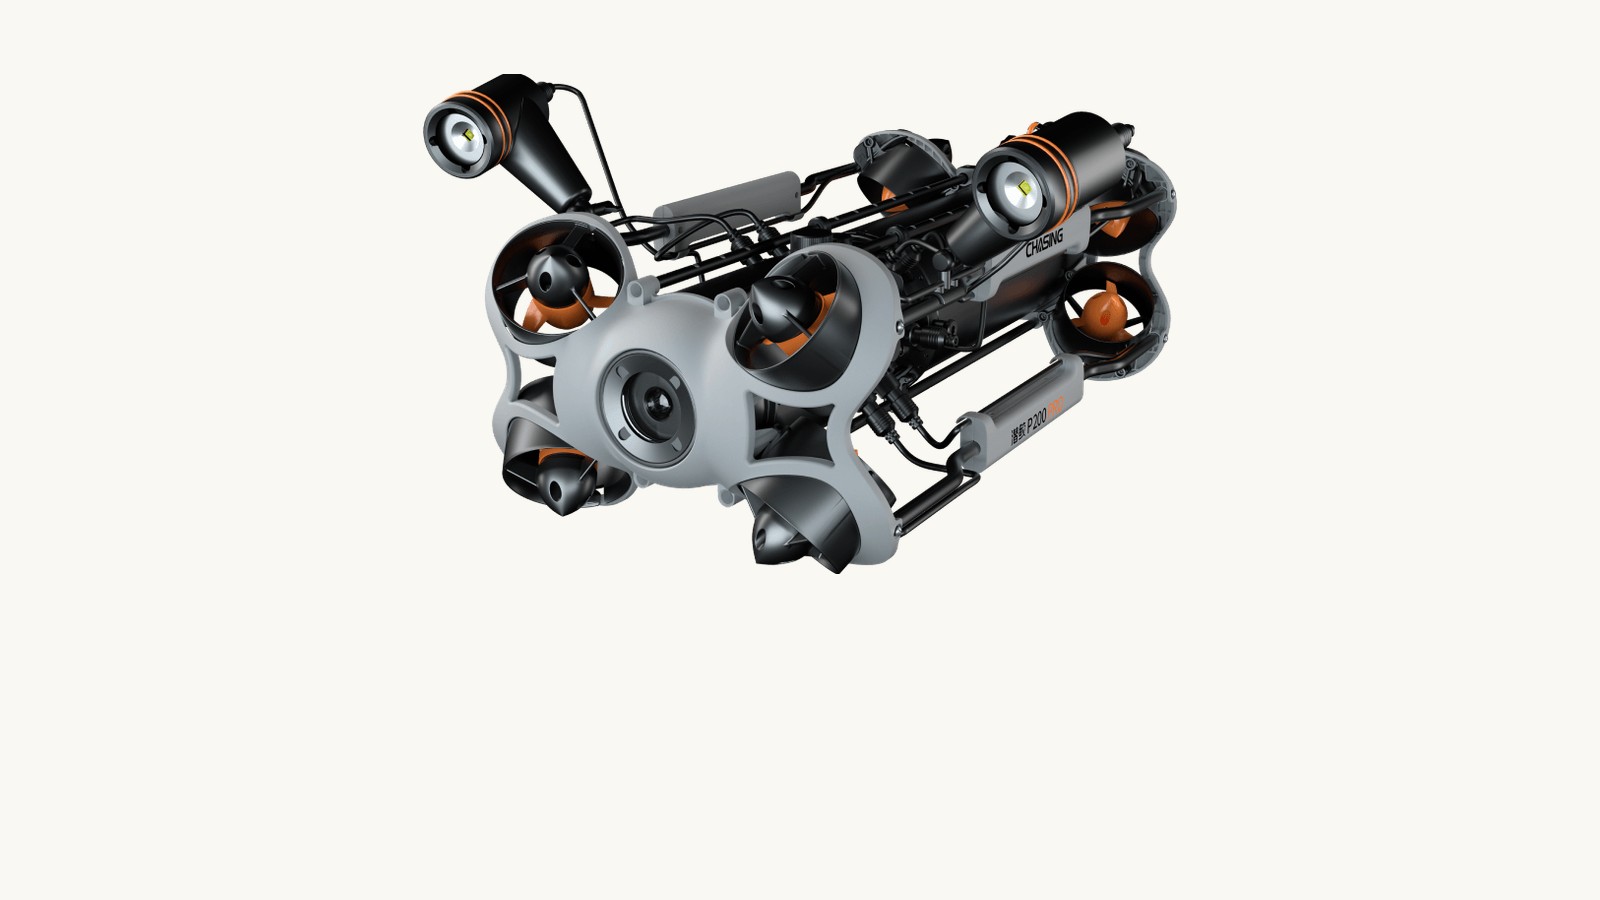
Underwater: the CHASING Qianjiao P200 Pro ROV
The platform's first underwater robot arrives with six cards: attitude/depth/position, status, battery, IMU, a live RTSP camera and six-degree-of-freedom motion control. MAVLink over UDP, with a one-second heartbeat that refuses to move if the link has been quiet for three seconds.
It speaks nine languages now
Two new speech engines: kokoro-multi covers nine languages with a runtime dropdown, and mms-th adds Thai. Engines are renamed <model>-<languages>, with the old names still resolving. Numbers in English sentences are no longer read in Chinese, and re-applying a config no longer costs seconds per utterance.
Your robot can tell who you are
A new face_recognition card enrolls a face from a photo or a link and then says who is in frame, with a confidence figure. Inference and the face database both stay on the robot; JetPack 5.11 machines run it on the GPU.
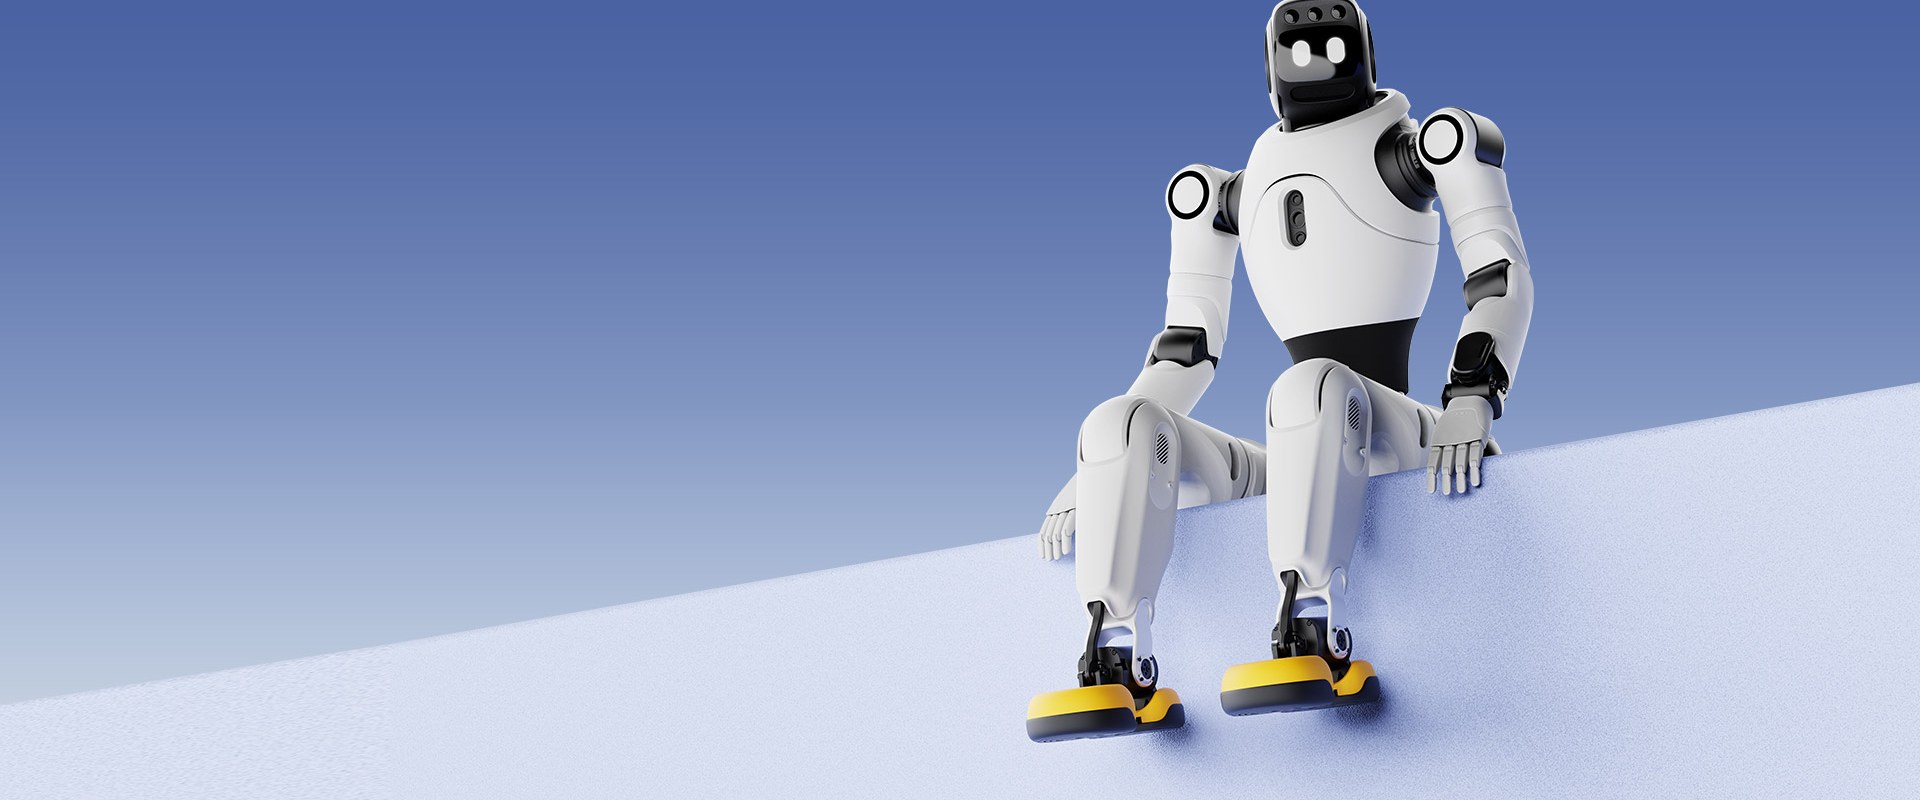
AgiBot X2 humanoid now supported
The AgiBot X2 joins the platform with 23 MCP cards — locomotion, 26 preset motions, dexterous hands, Linkcraft motion library, RGB-D + lidar + SLAM, TTS, expressions and LED.
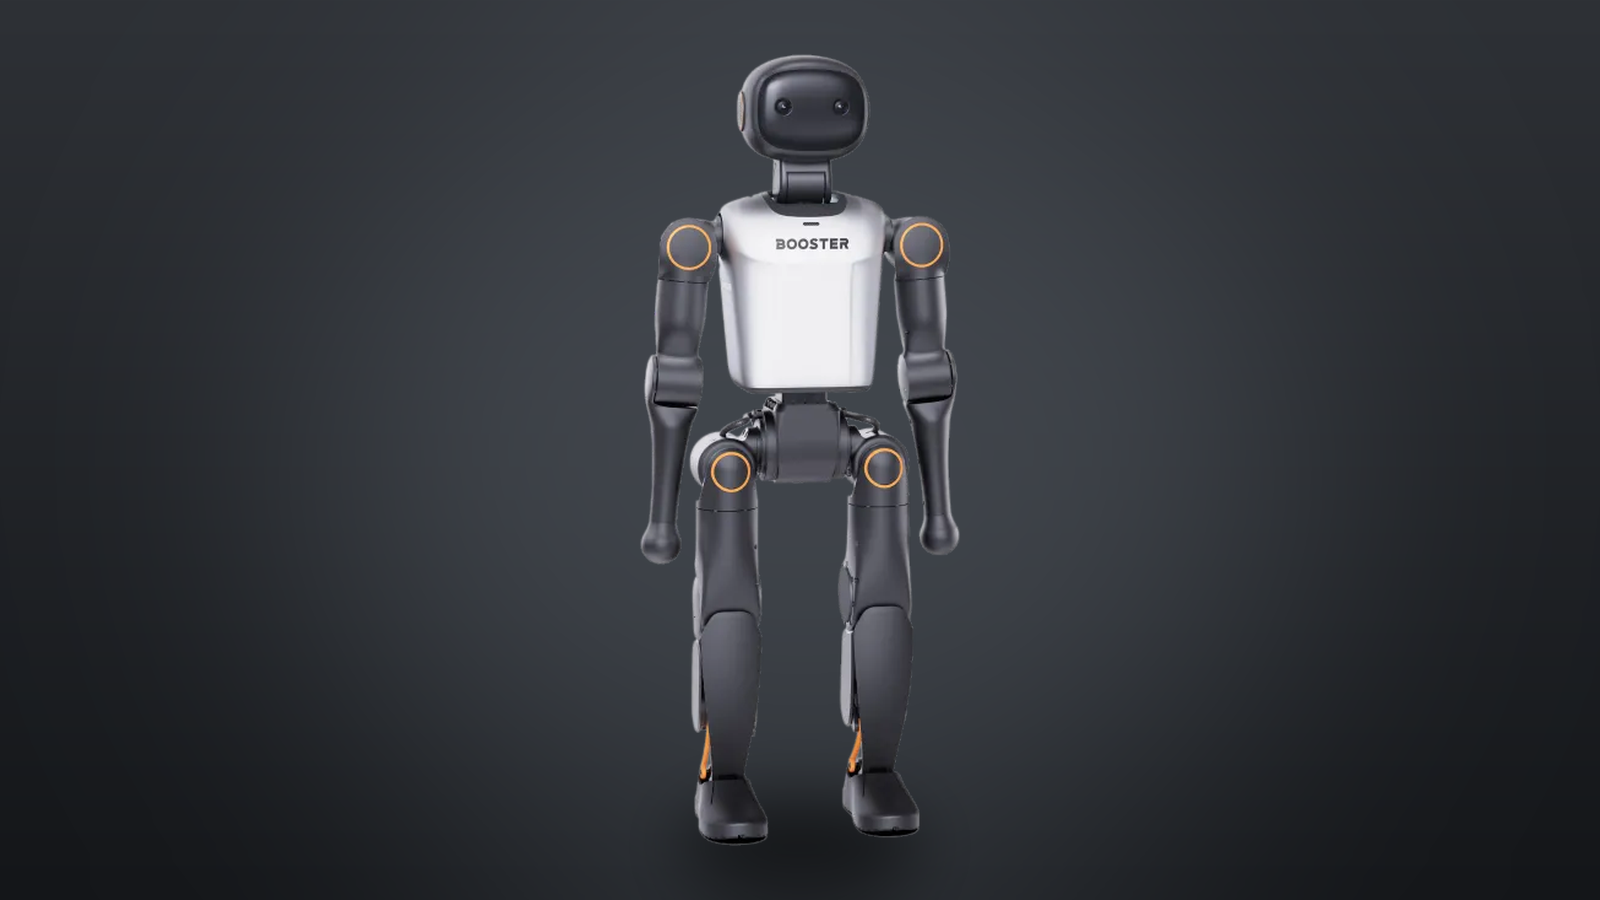
Booster K1 joins the platform — a walking humanoid your agent can drive
The Booster K1 bipedal humanoid now has a first-class driver: walking, gait and mode switching, head aiming, upper-body joint control, preset actions, get-up, trajectory playback, audio and vision — all as tools your agent can call.
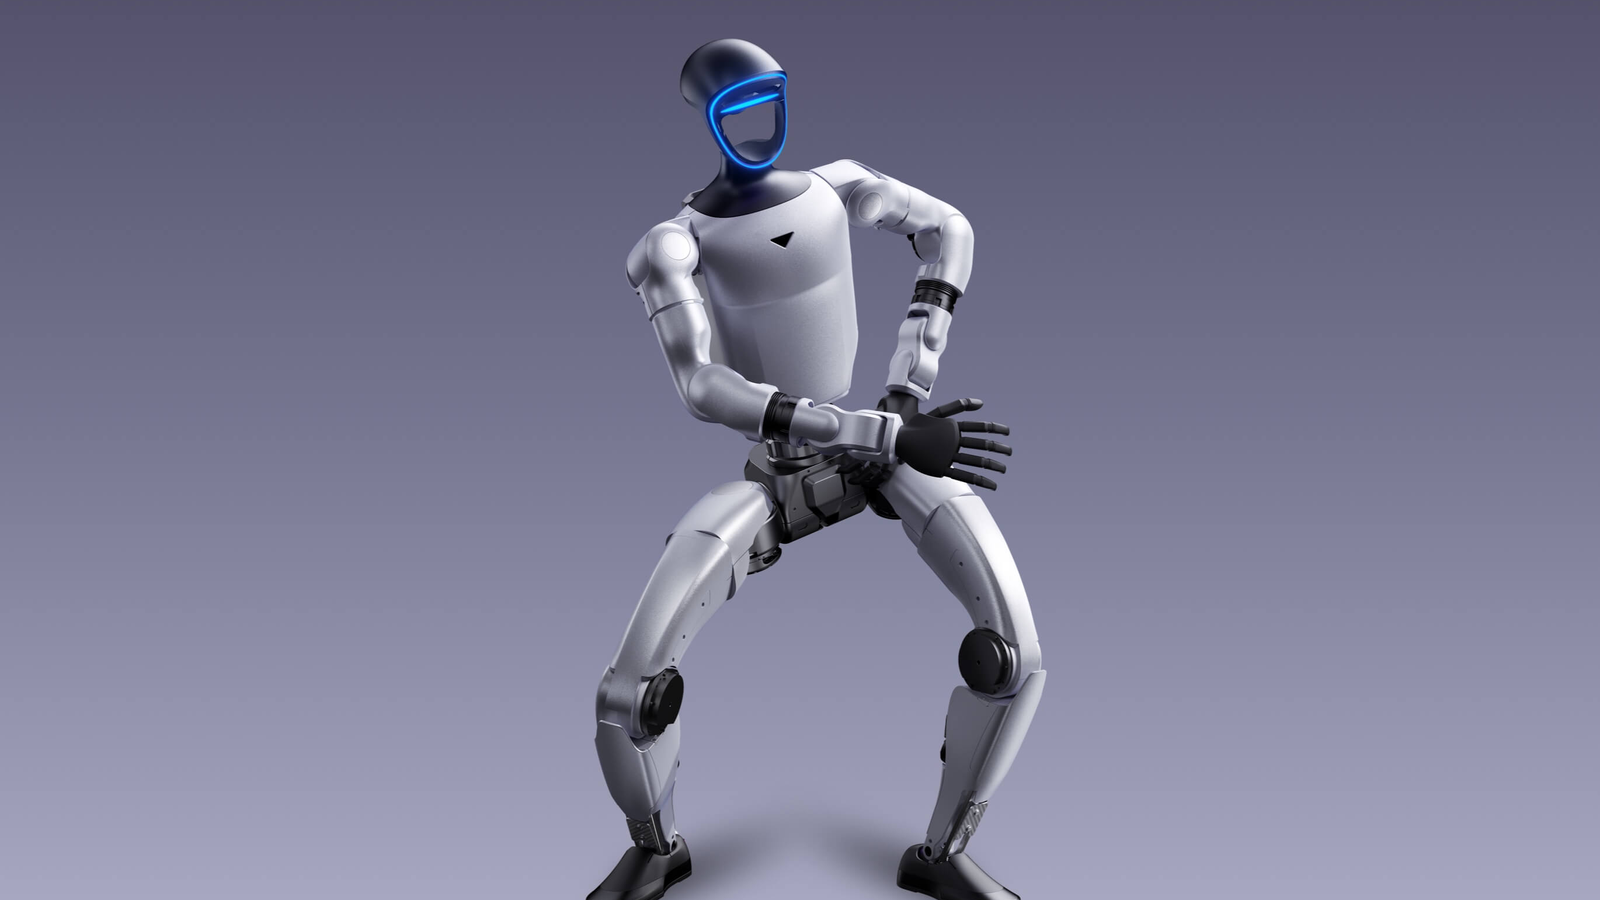
G1 gets up from a squat again — and reports the posture it is really in
A G1 that squatted could not stand back up: the stand-up call reported "robot is on ground" and bounced between states. Fixed on the real robot, along with the deeper confusion between control mode and physical posture.
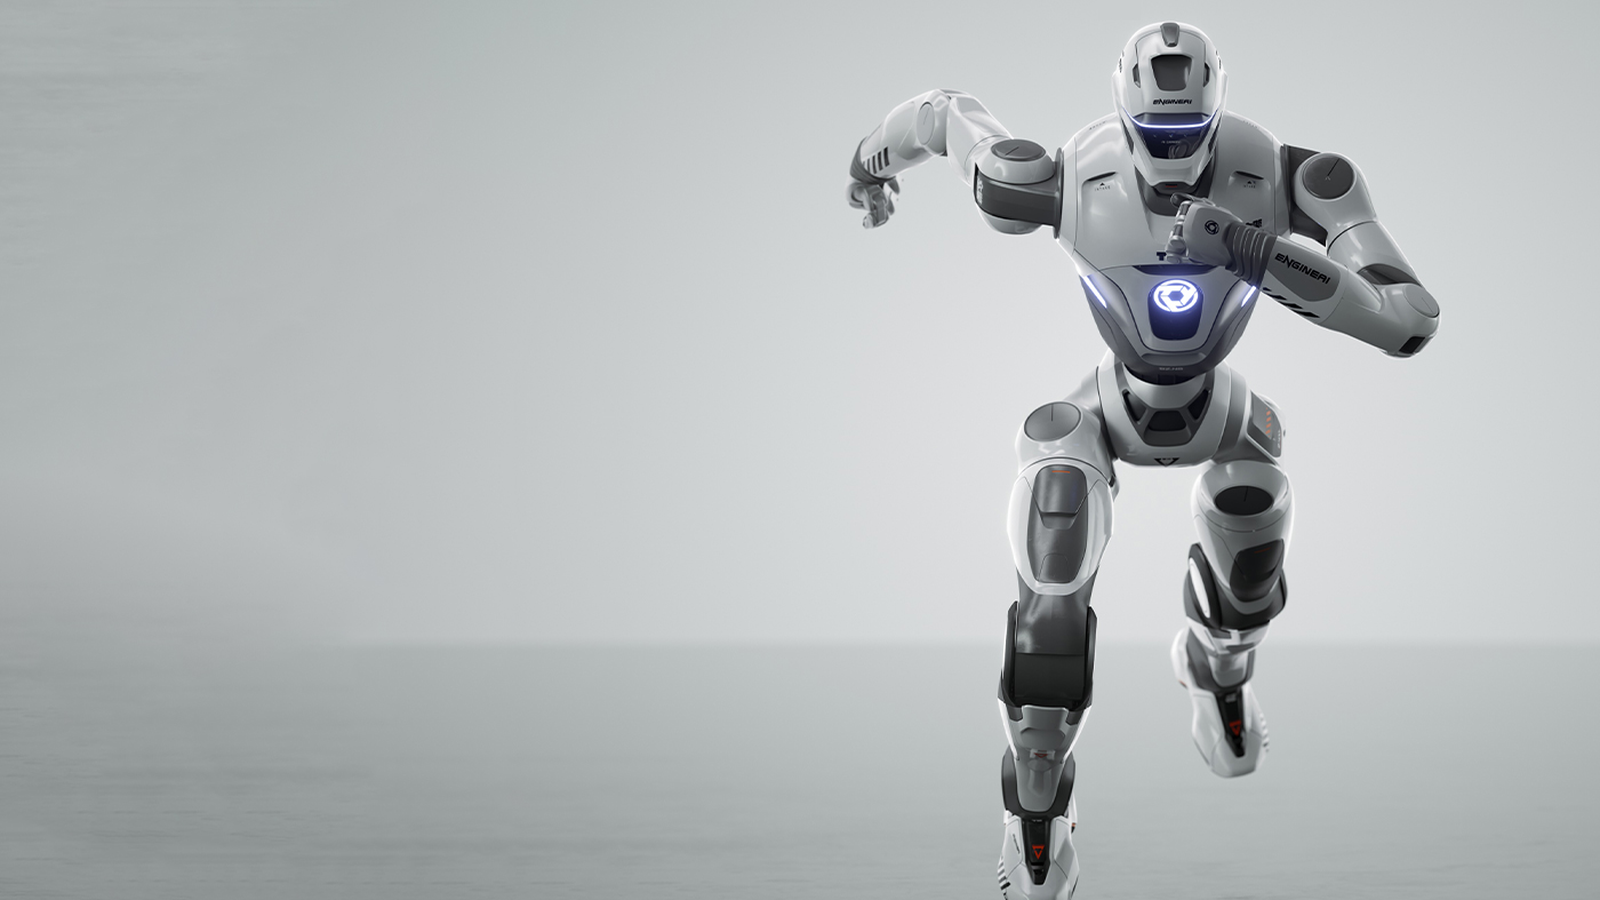
T800 can now walk, speak and remember a motion you taught it
The EngineAI T800 driver grows a speaker, walking with real gaits, a motion recorder, and a posture switch that always routes through standing — plus honest state reporting instead of guesses.
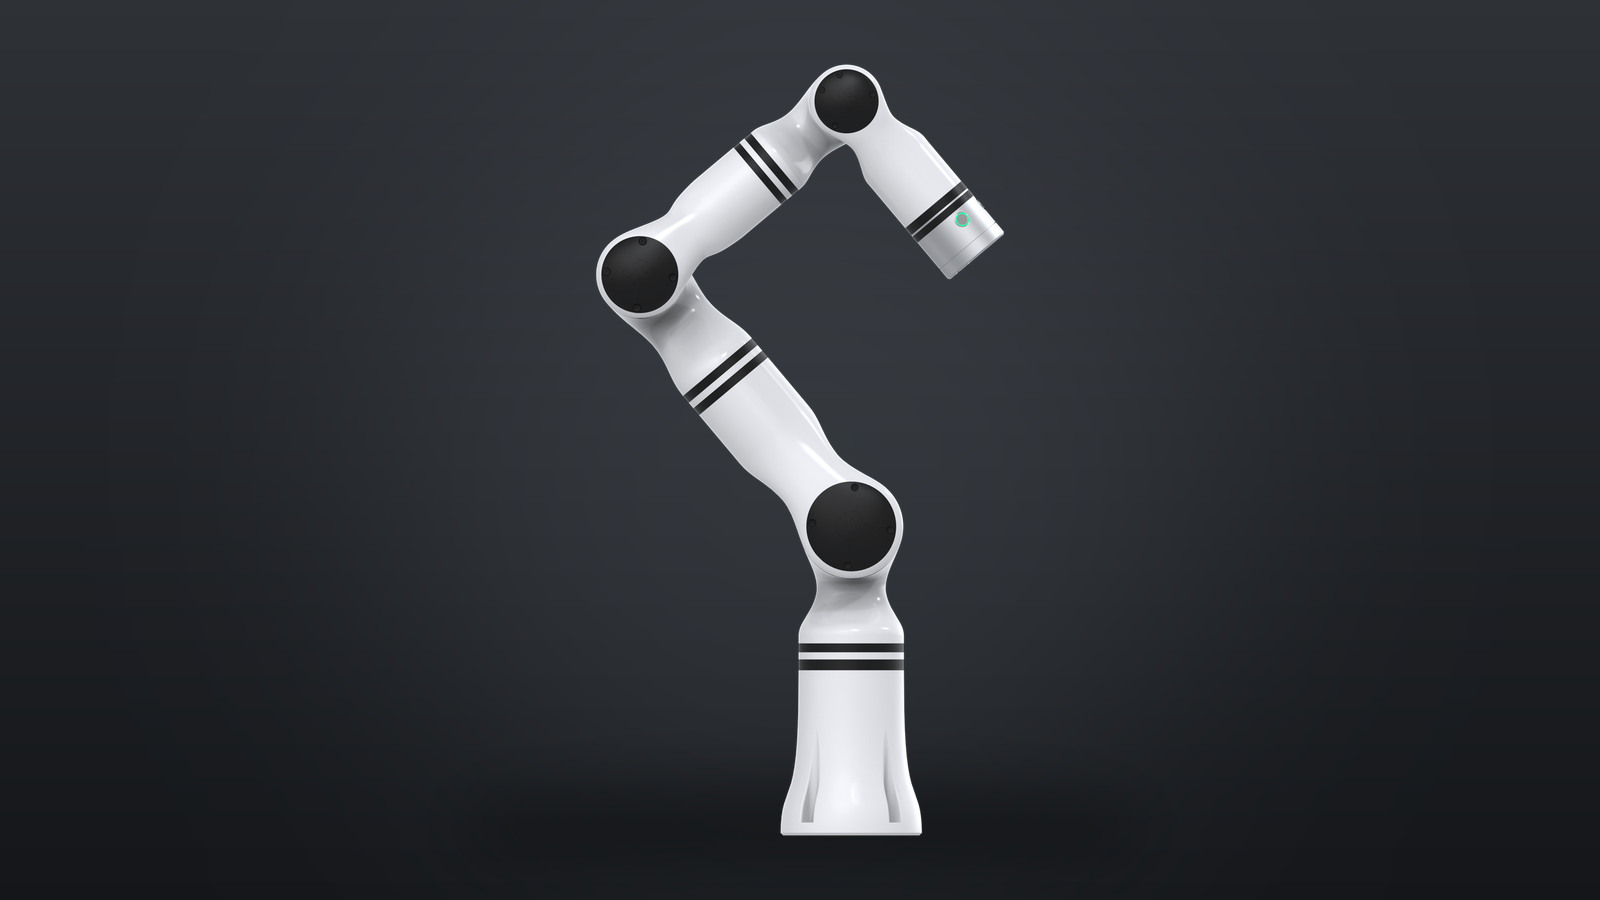
RealMan RM75-6F-V — a 7-axis arm your robot's AI can drive safely
The RealMan RM75-6F-V driver is available. Seven joints in one card, a pre-move self-check that refuses unsafe commands instead of moving first, motion that only reports done when the arm has actually arrived, a full set of live state cards, and a 3D skeleton view.
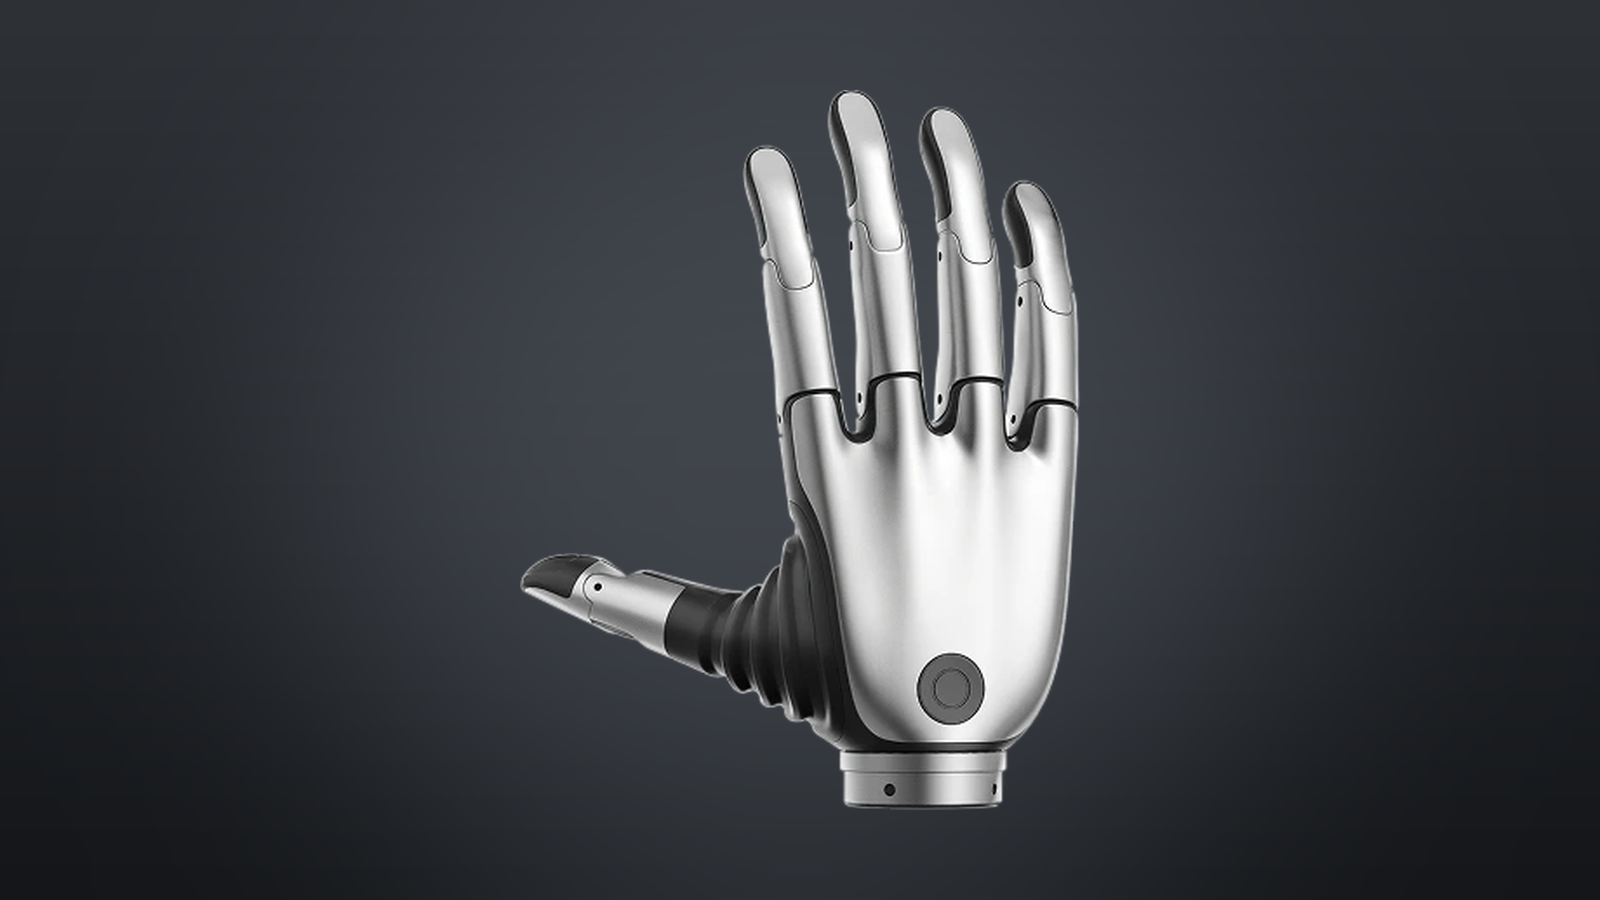
BrainCo Revo 2 — a dexterous hand your agent can actually grasp with
The BrainCo Revo 2 dexterous hand now has a driver: open and close, per-finger positions, preset gestures, live joint telemetry, LED and button events, and fingertip touch on the tactile model — with two hands on one bus.